A rideable prototype
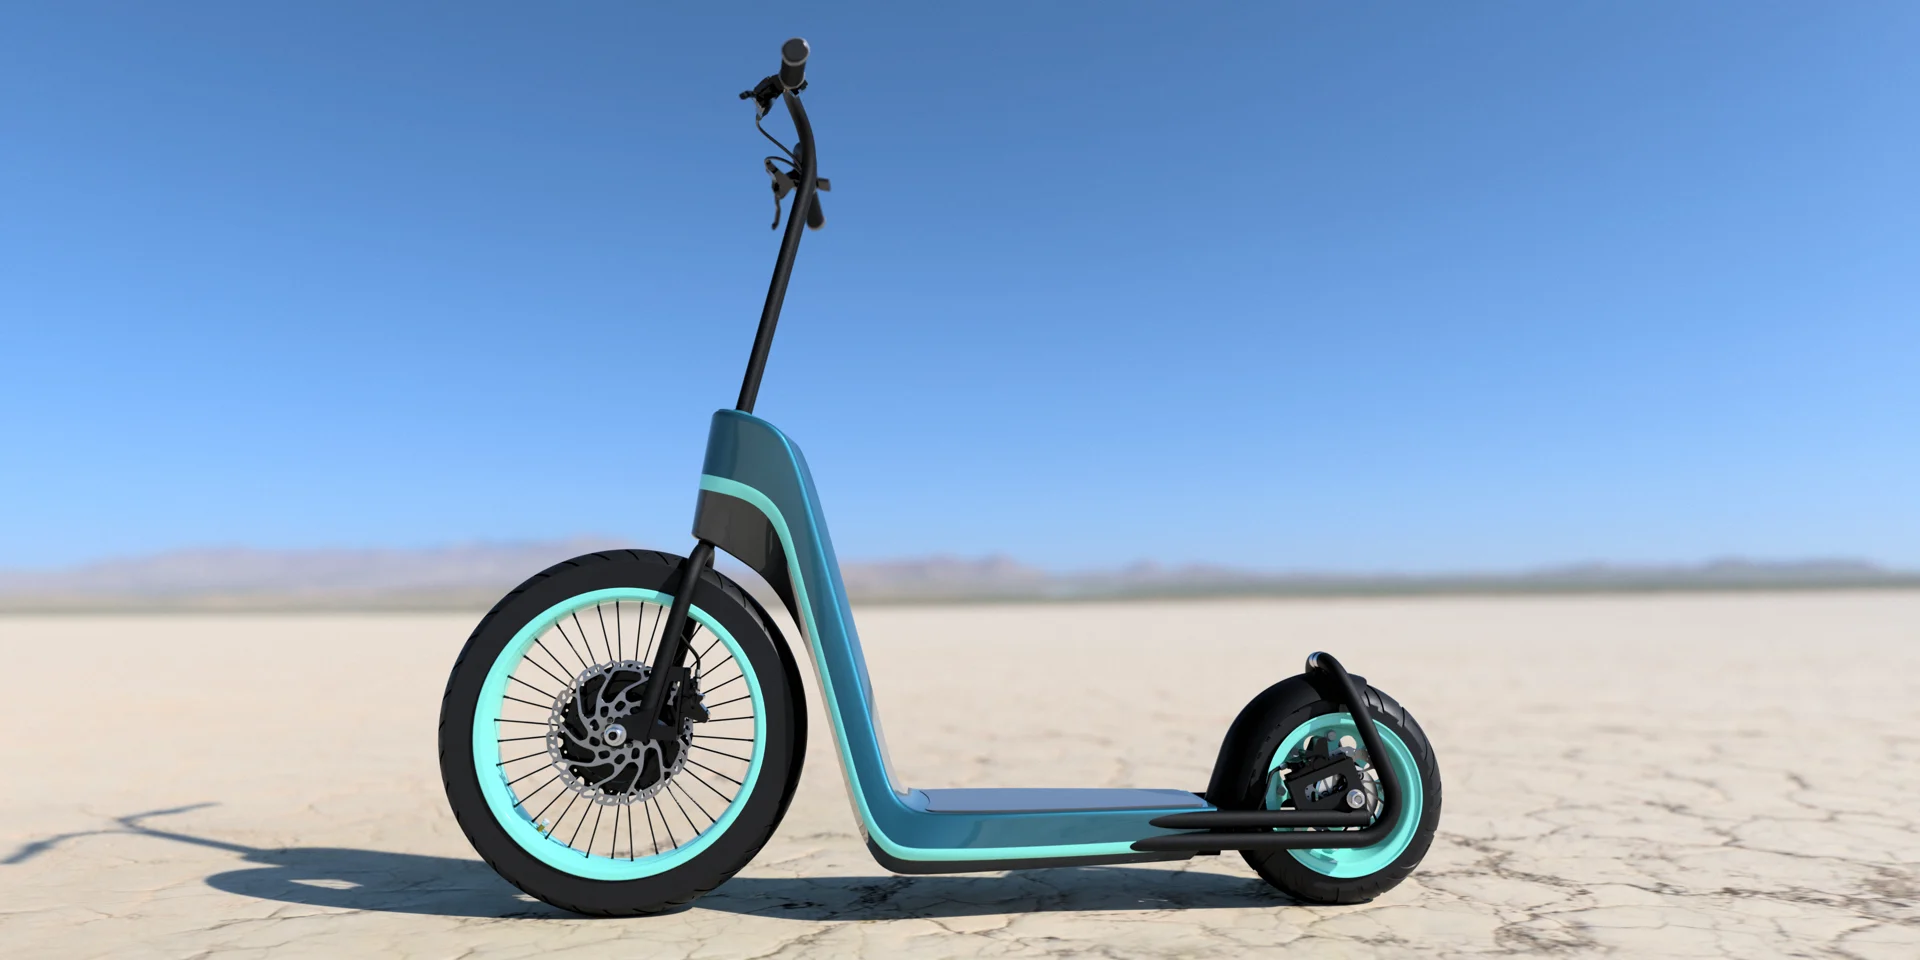
We completed a rideable prototype in spring 2019. The test ride below shows the working vehicle; self-balancing and autonomous driving remained goals for further development.
Rethinking the vehicle and the service
The project began in 2018. Our design priorities were wheel size, center of gravity, braking and frame geometry. We also considered the work involved in collecting, charging and redistributing shared scooters.
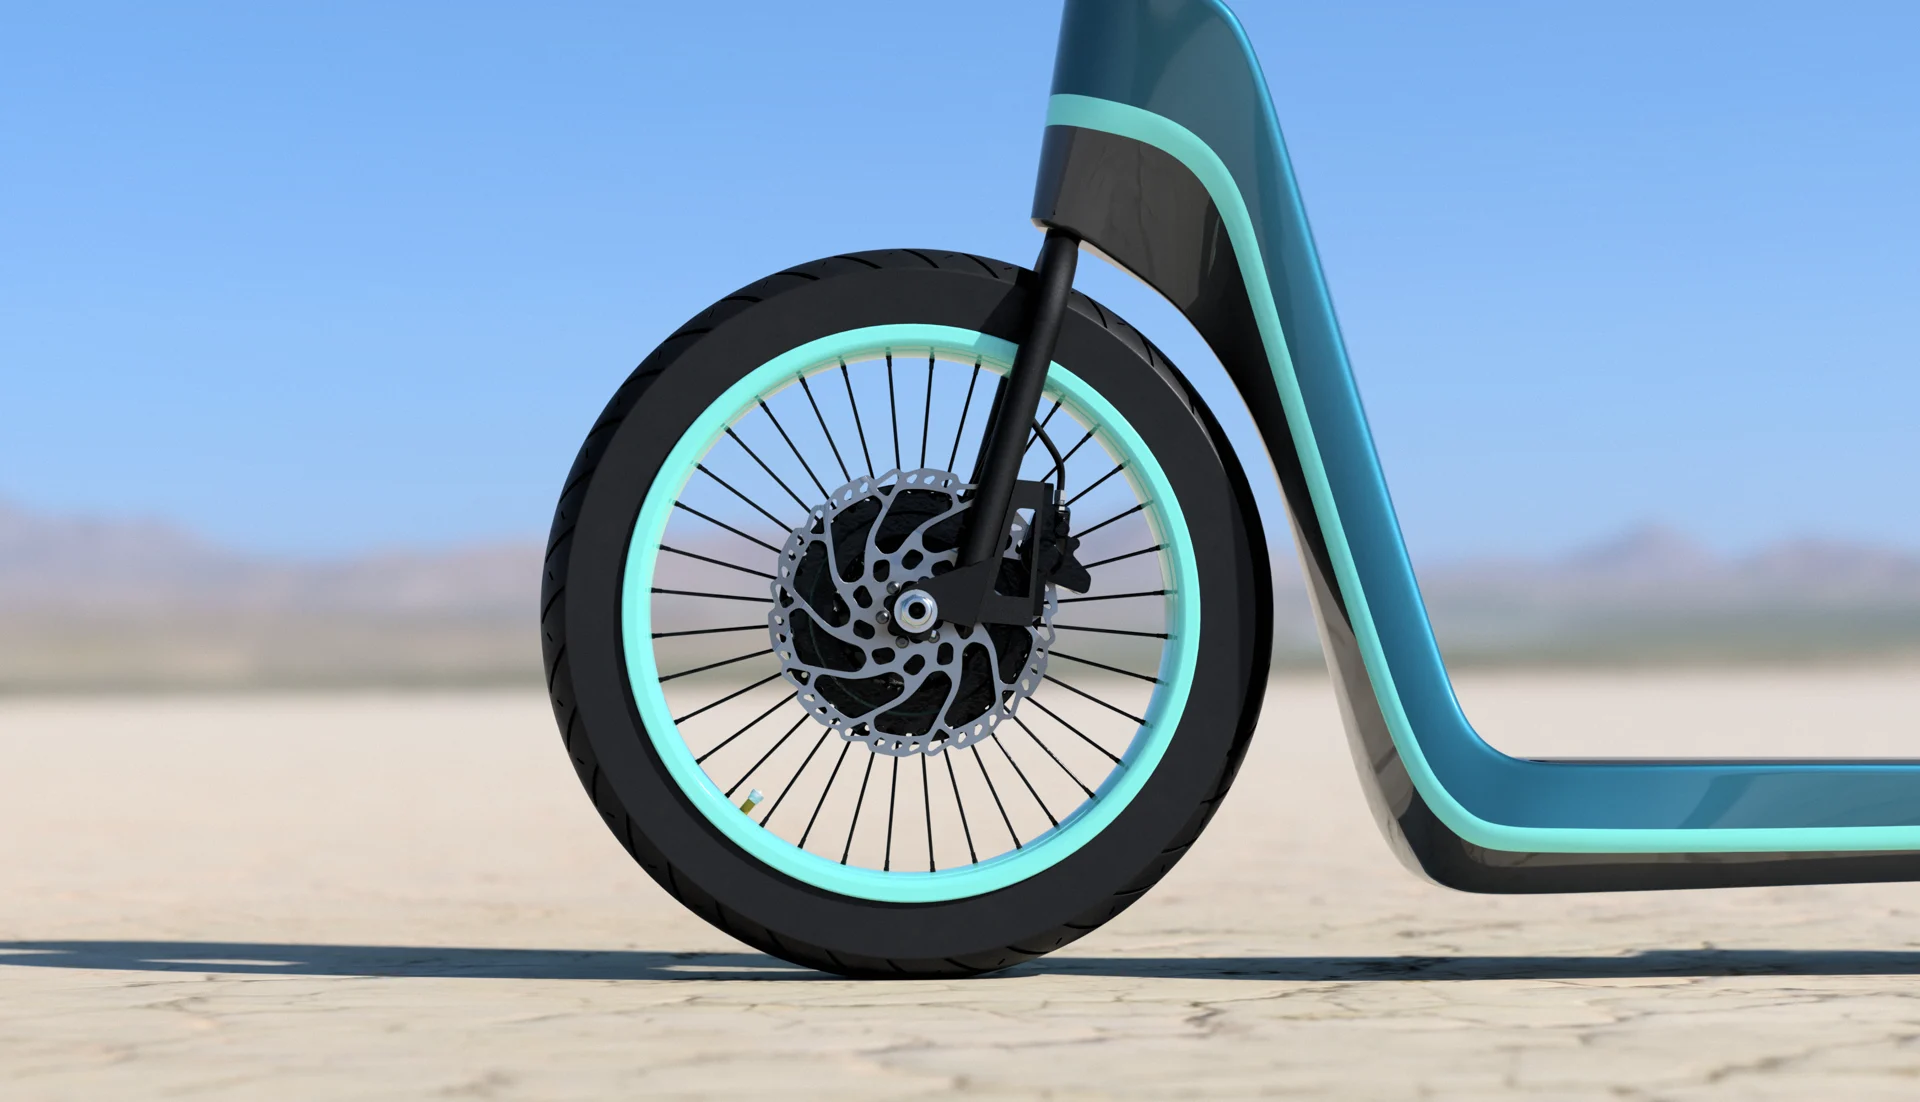
A 20-inch pneumatic front wheel was a defining feature. It was selected to improve the scooter's ability to handle uneven surfaces and to provide cushioning without suspension. The larger wheel also accommodated a geared e-bike hub motor and reserved space for future self-balancing hardware.
Building the prototype
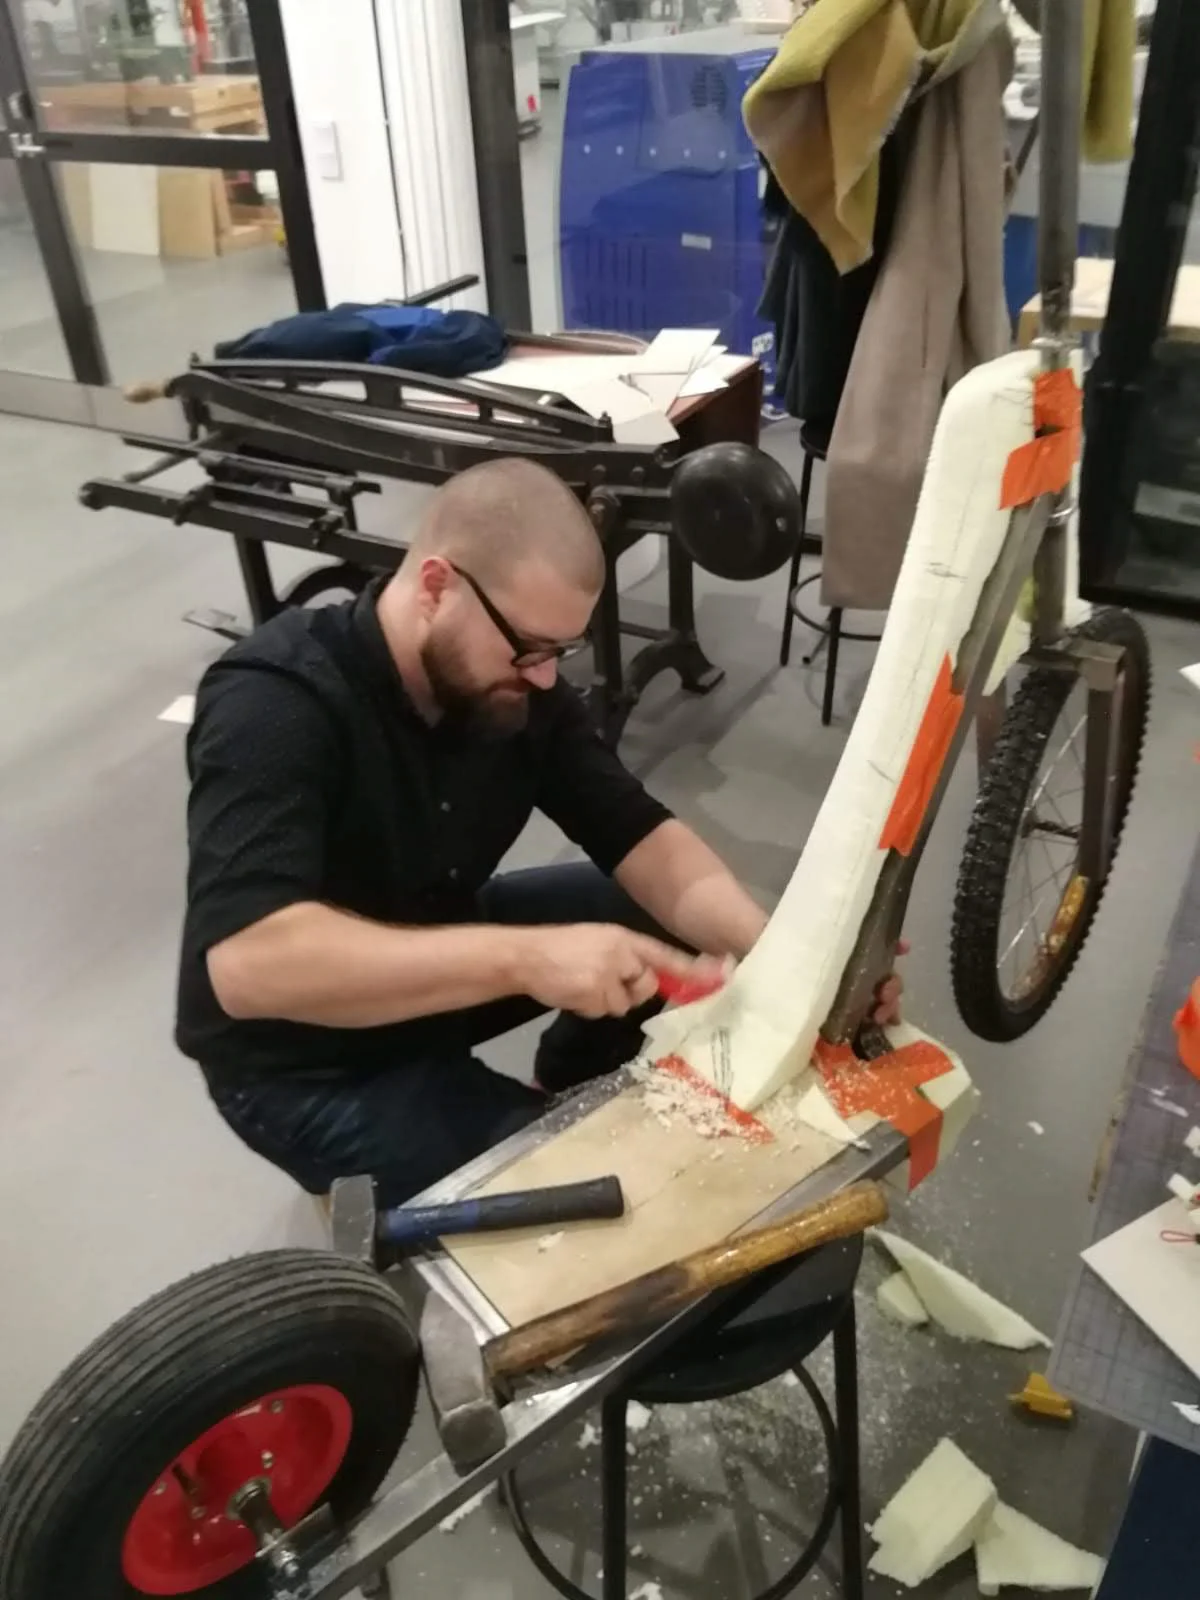
We progressed from geometry mockups and foam models to a welded frame, electrical assembly and a working vehicle. Alongside the engineering work, we refined the relationship between the twin-tube frame and the body shell housing the battery and electronics.
Exploring the overall form
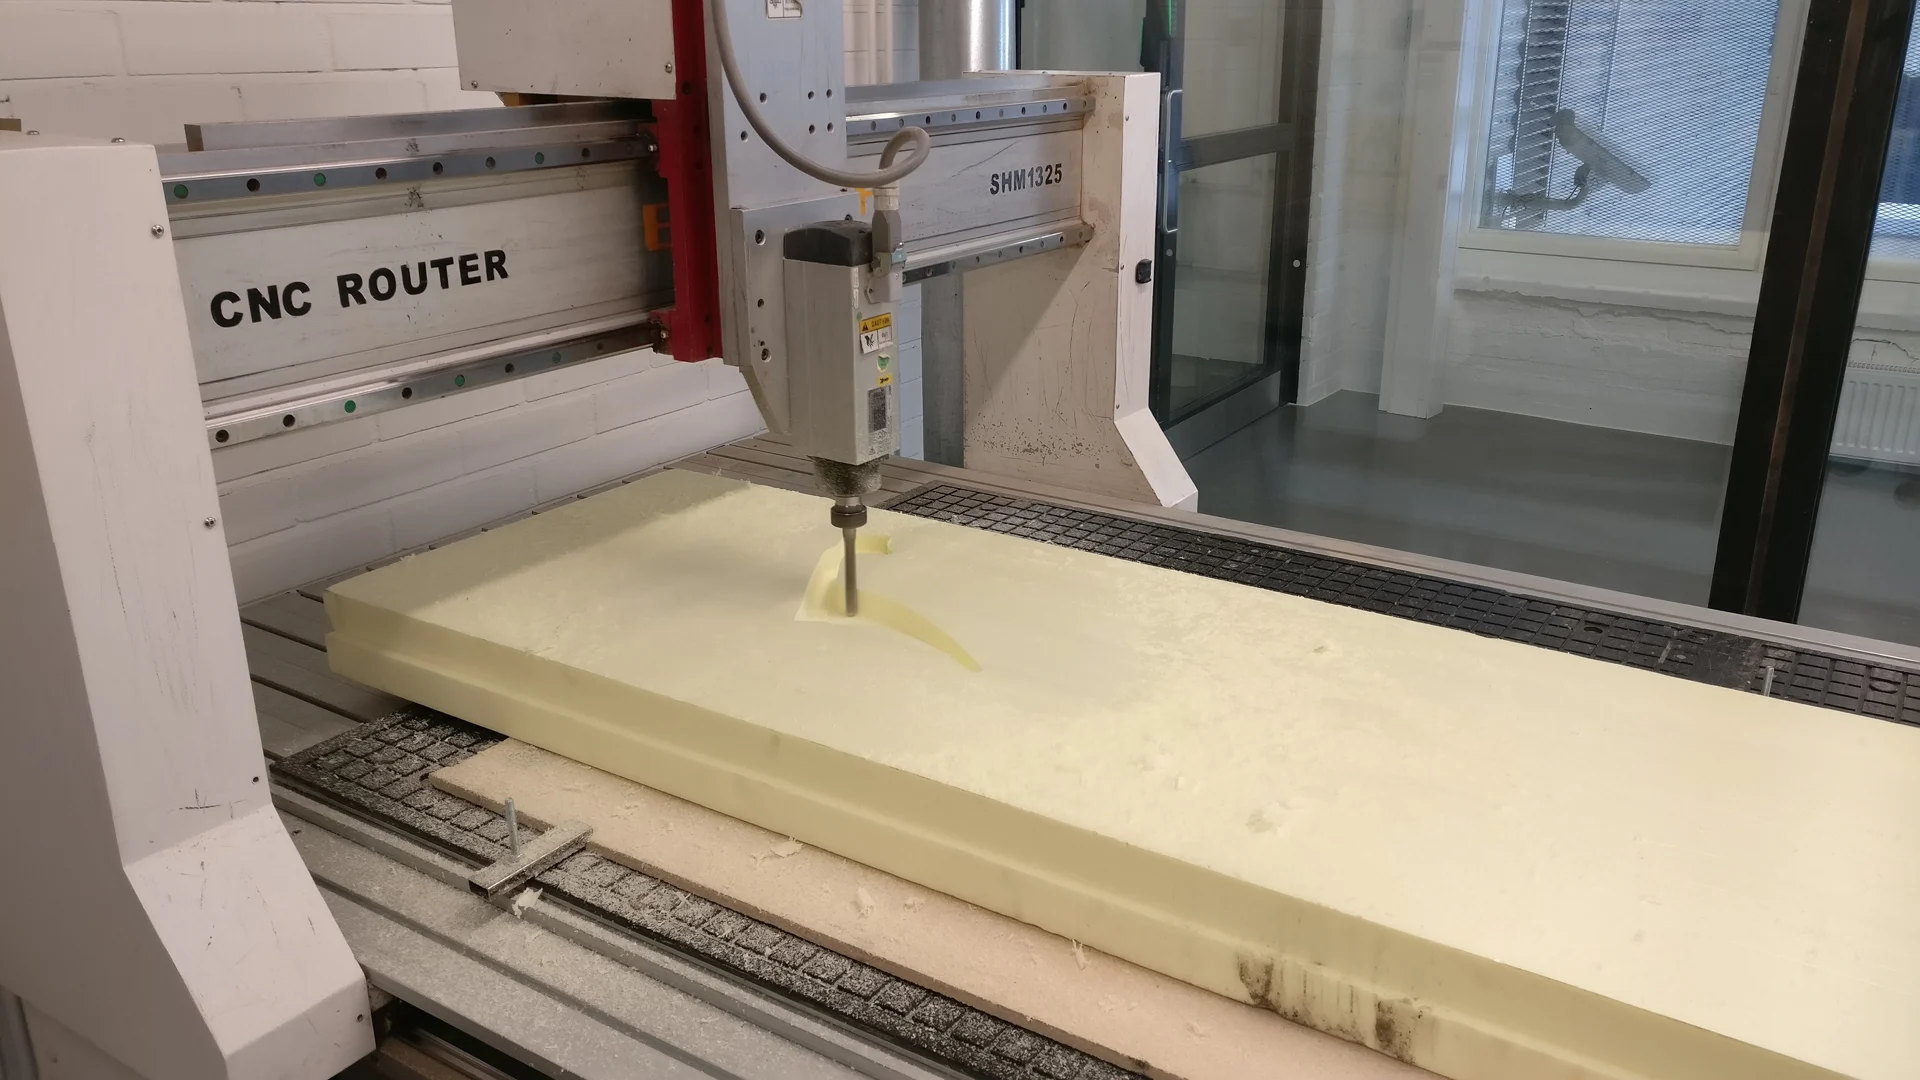
CNC-milling the first foam model
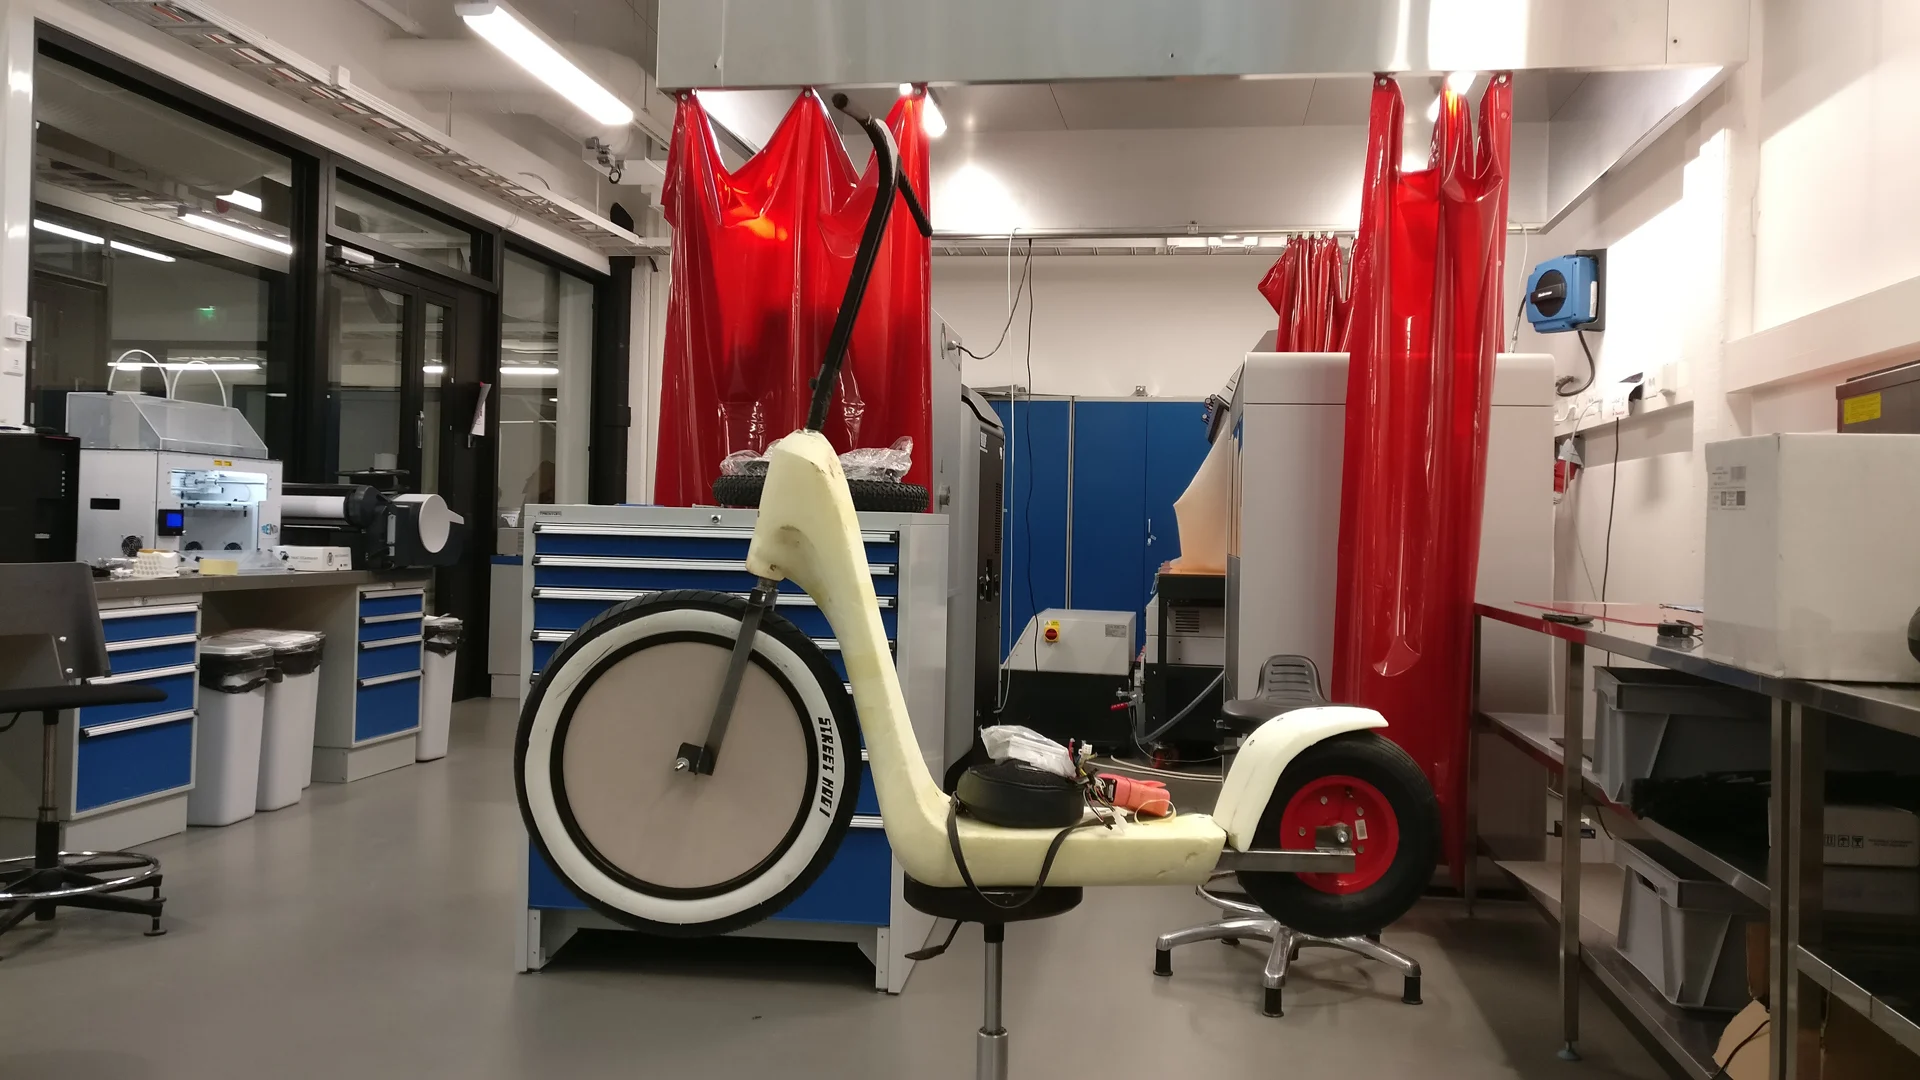
Bodywork mockup
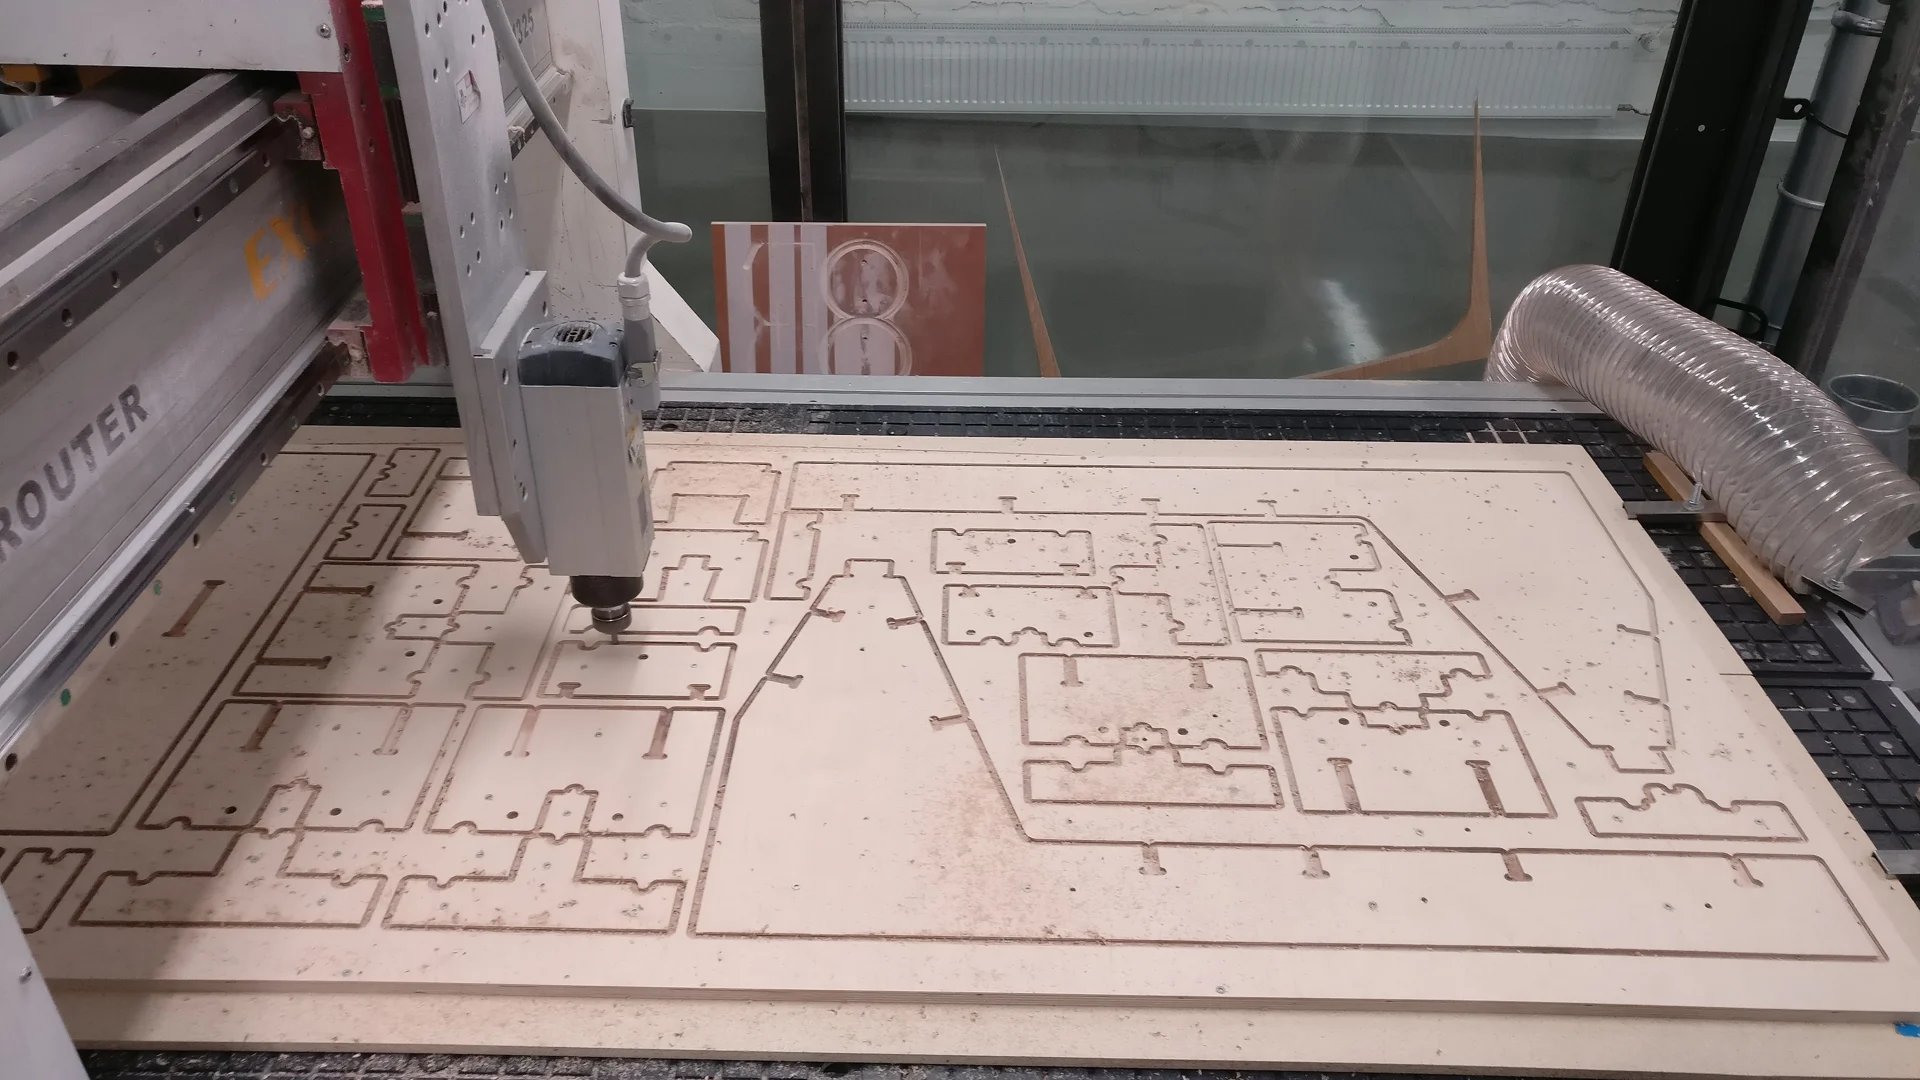
Machining the welding jig after finalizing the frame design
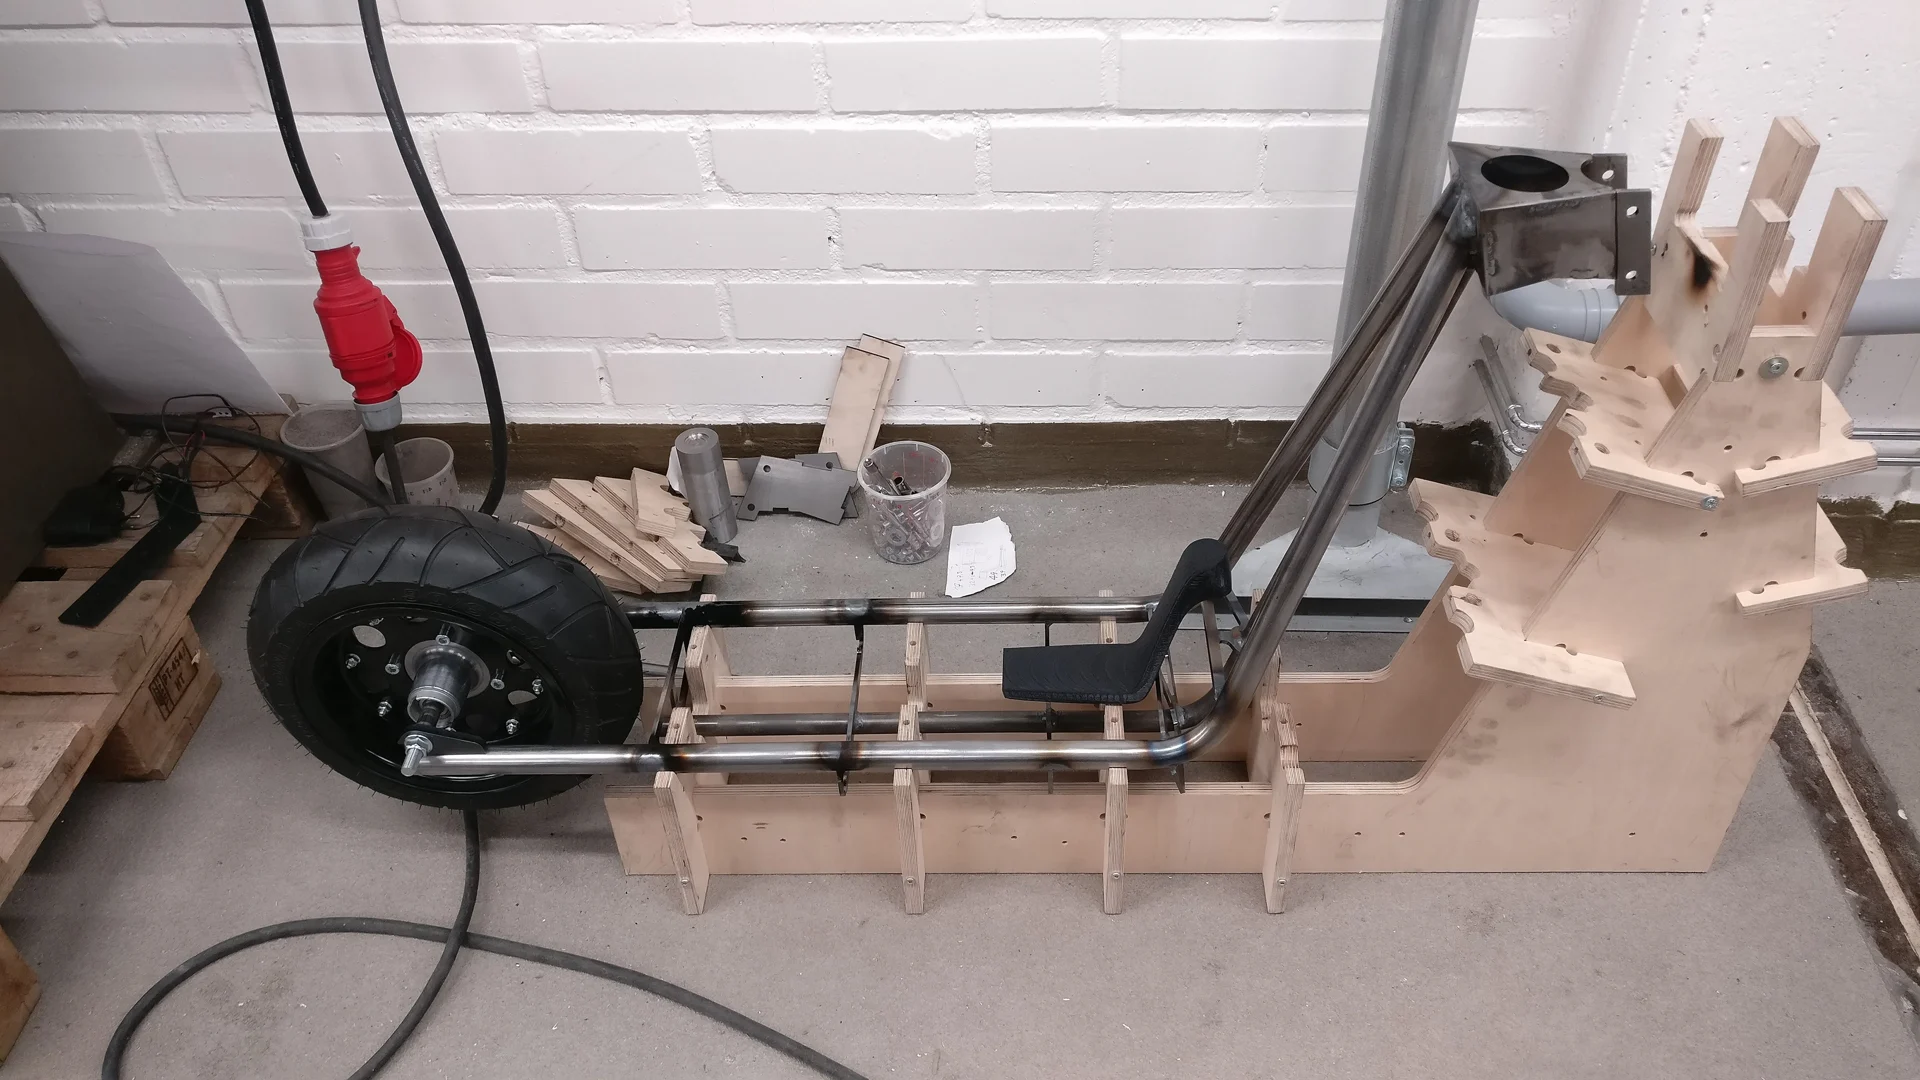
Frame assembly in progress
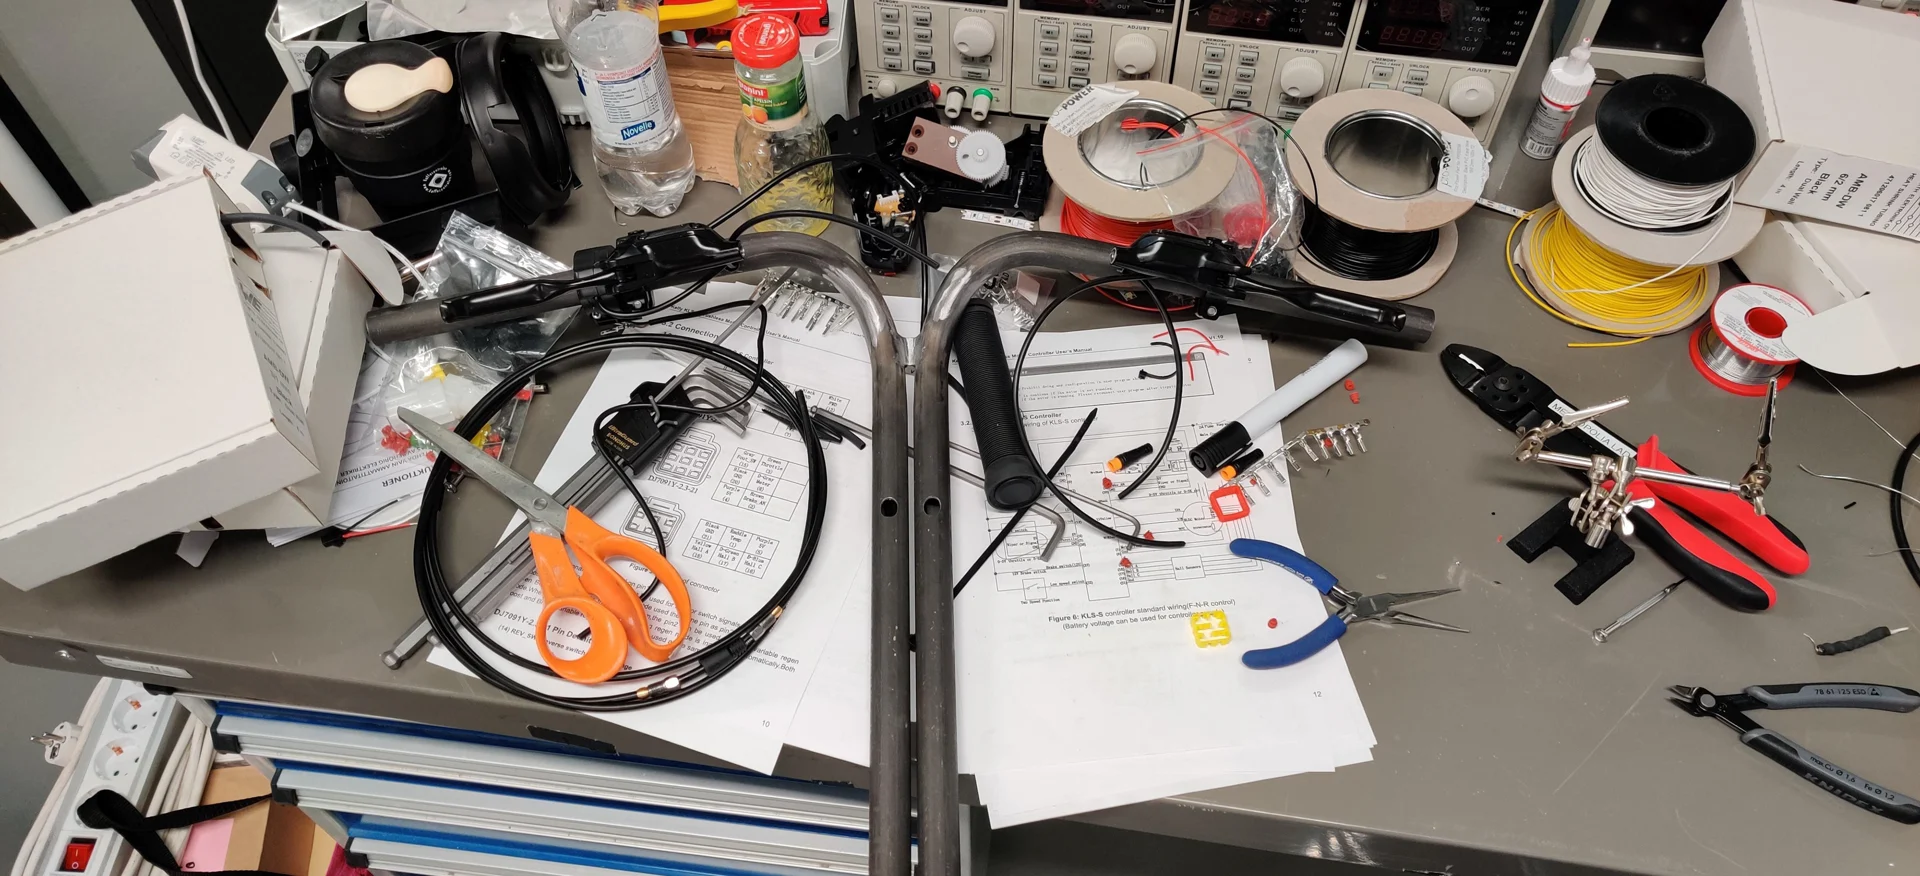
Wiring and electrical assembly
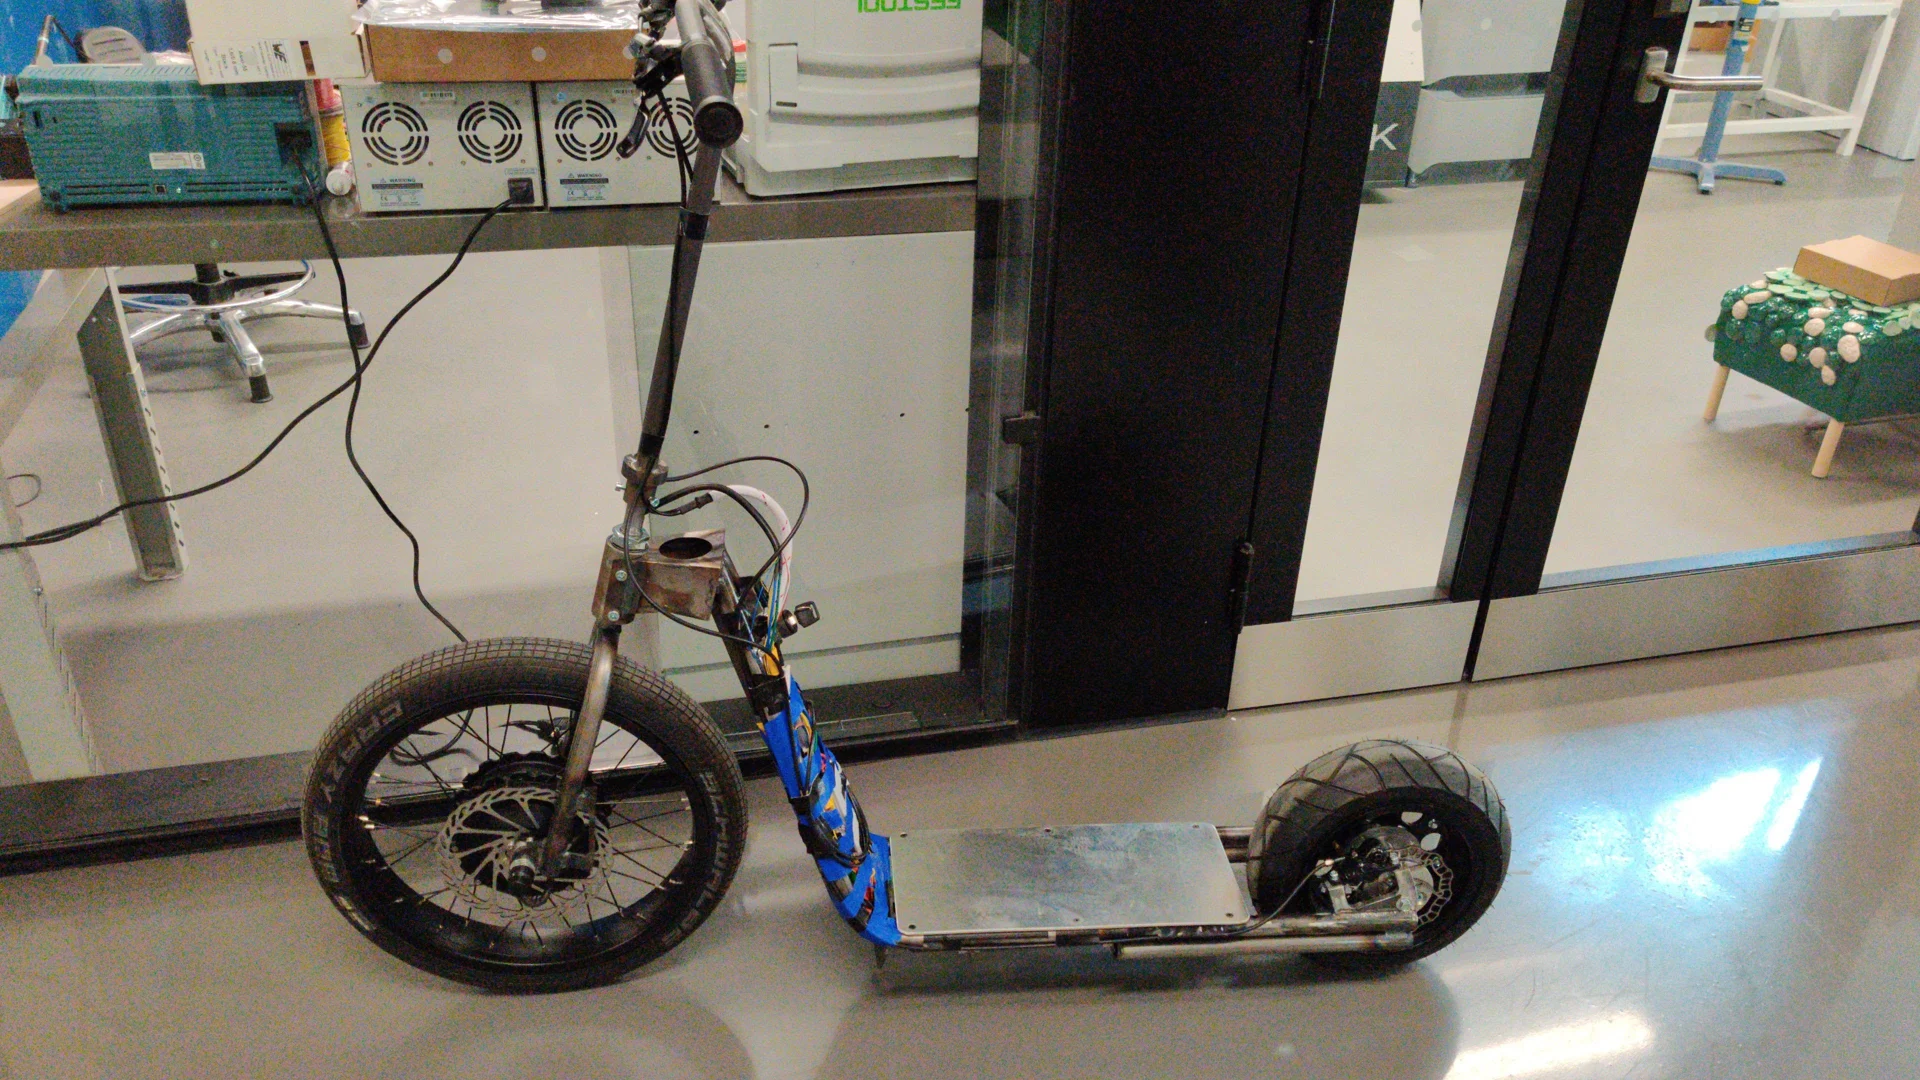
Rideable prototype, spring 2019
Further development
Our longer-term ambition was a scooter that could balance itself and travel autonomously to charging points or new pickup locations. The small-scale experimental prototype shown here explored the self-balancing concept.
The manufacturing and parking concepts below describe possible next steps beyond the completed rideable prototype.
Small-scale experimental prototype for the self-balancing concept
Exploring additive manufacturing
We explored a future version with a 3D-printed monocoque body made from carbon-fiber-reinforced thermoplastic. The proposed structure would incorporate a battery compartment, cable channels and pockets for steel inserts within the printed body.
The aim was to simplify assembly and allow the design to be adapted to different requirements. This remained a proposed manufacturing approach, separate from the completed prototype.
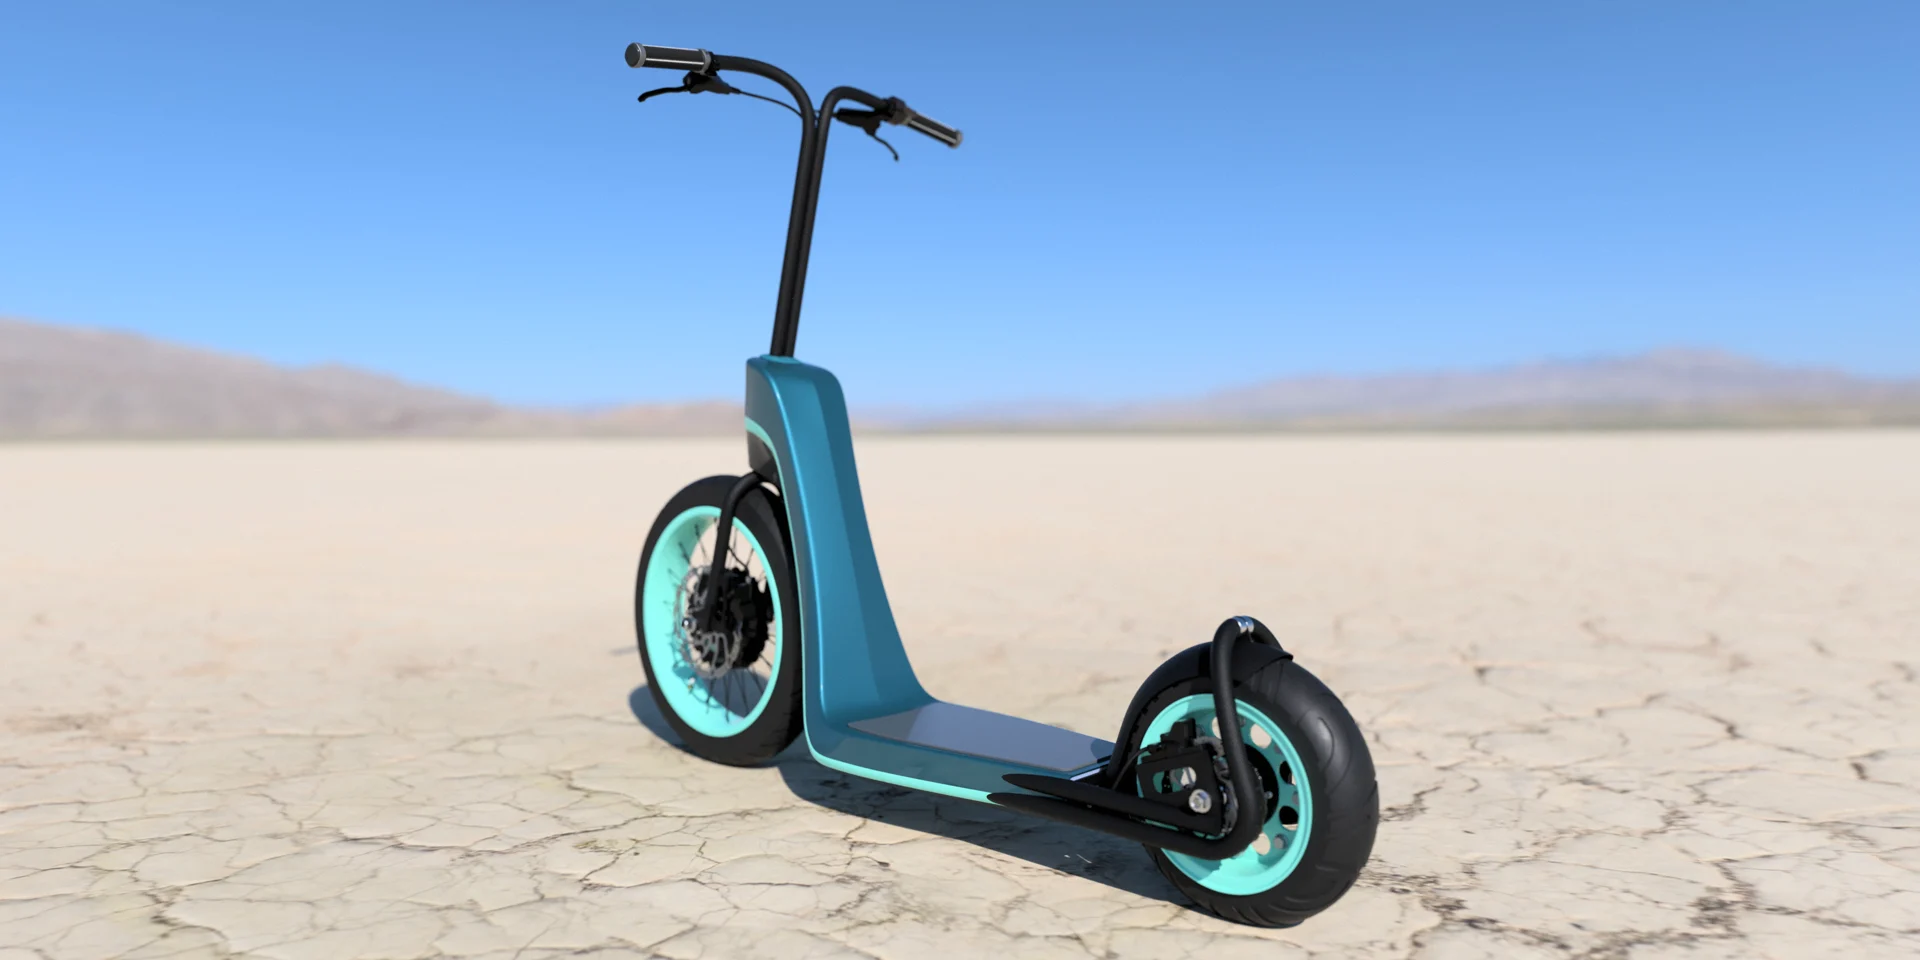
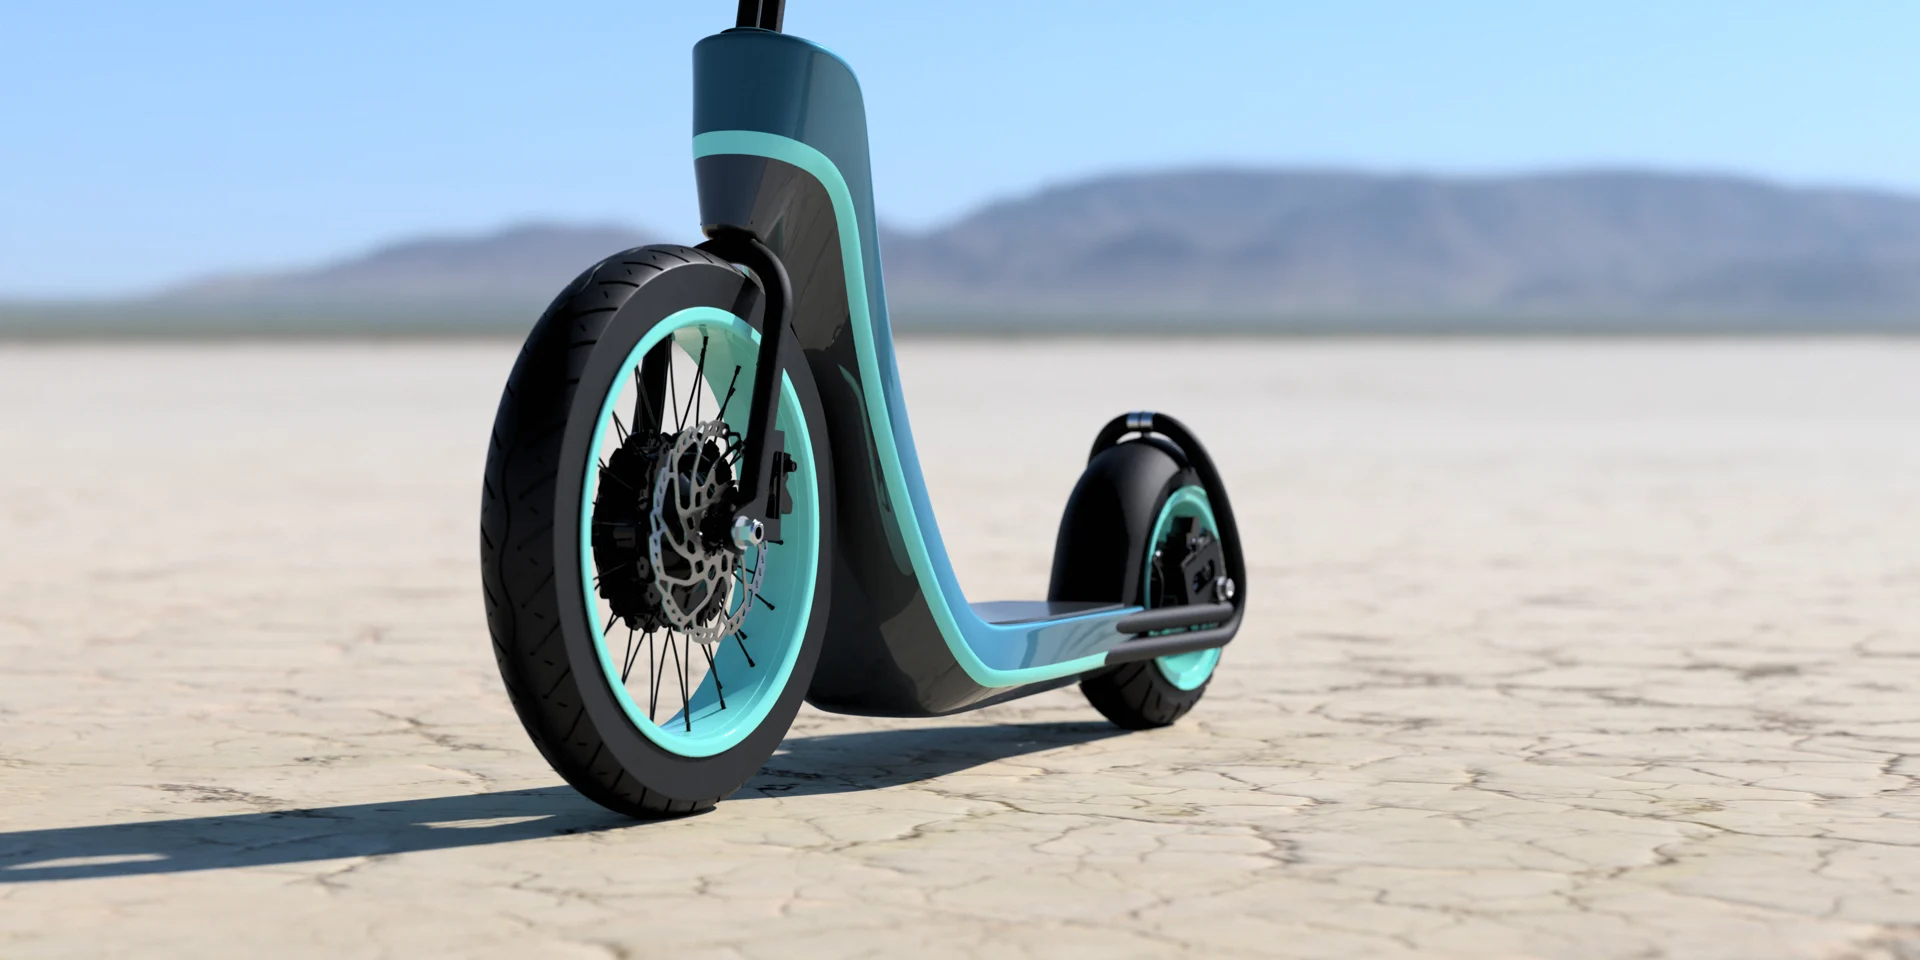
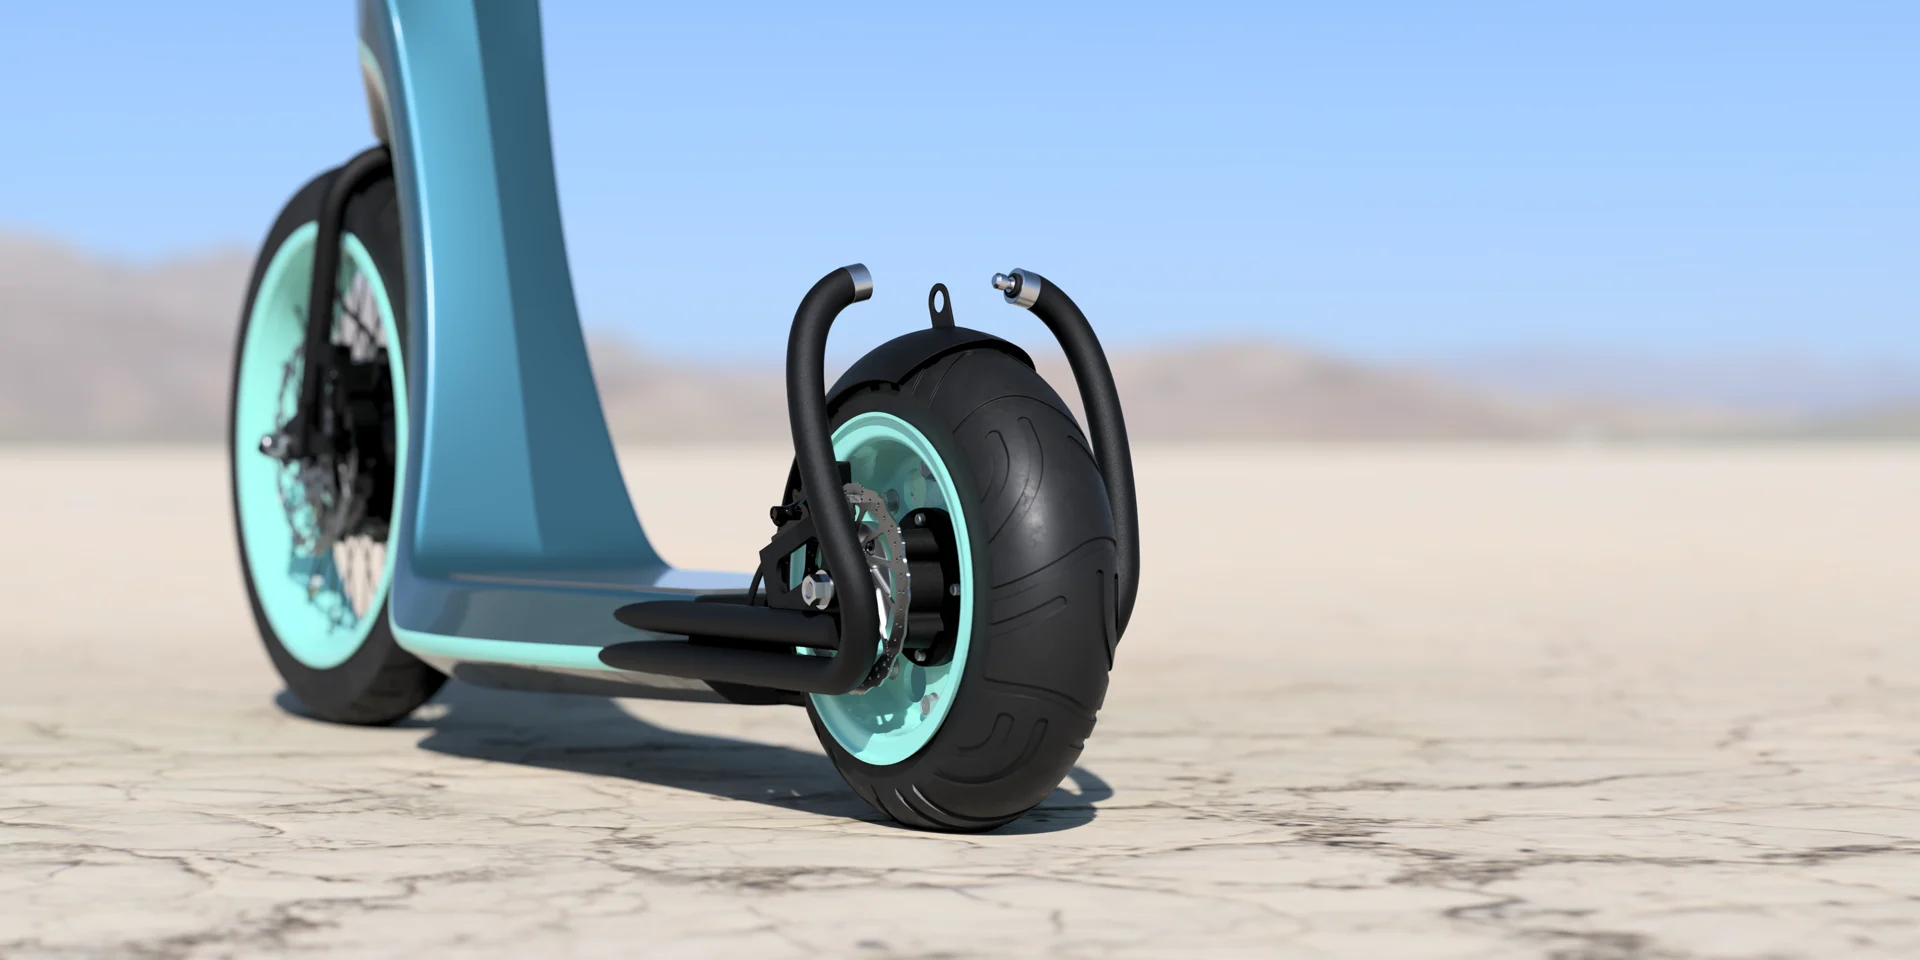
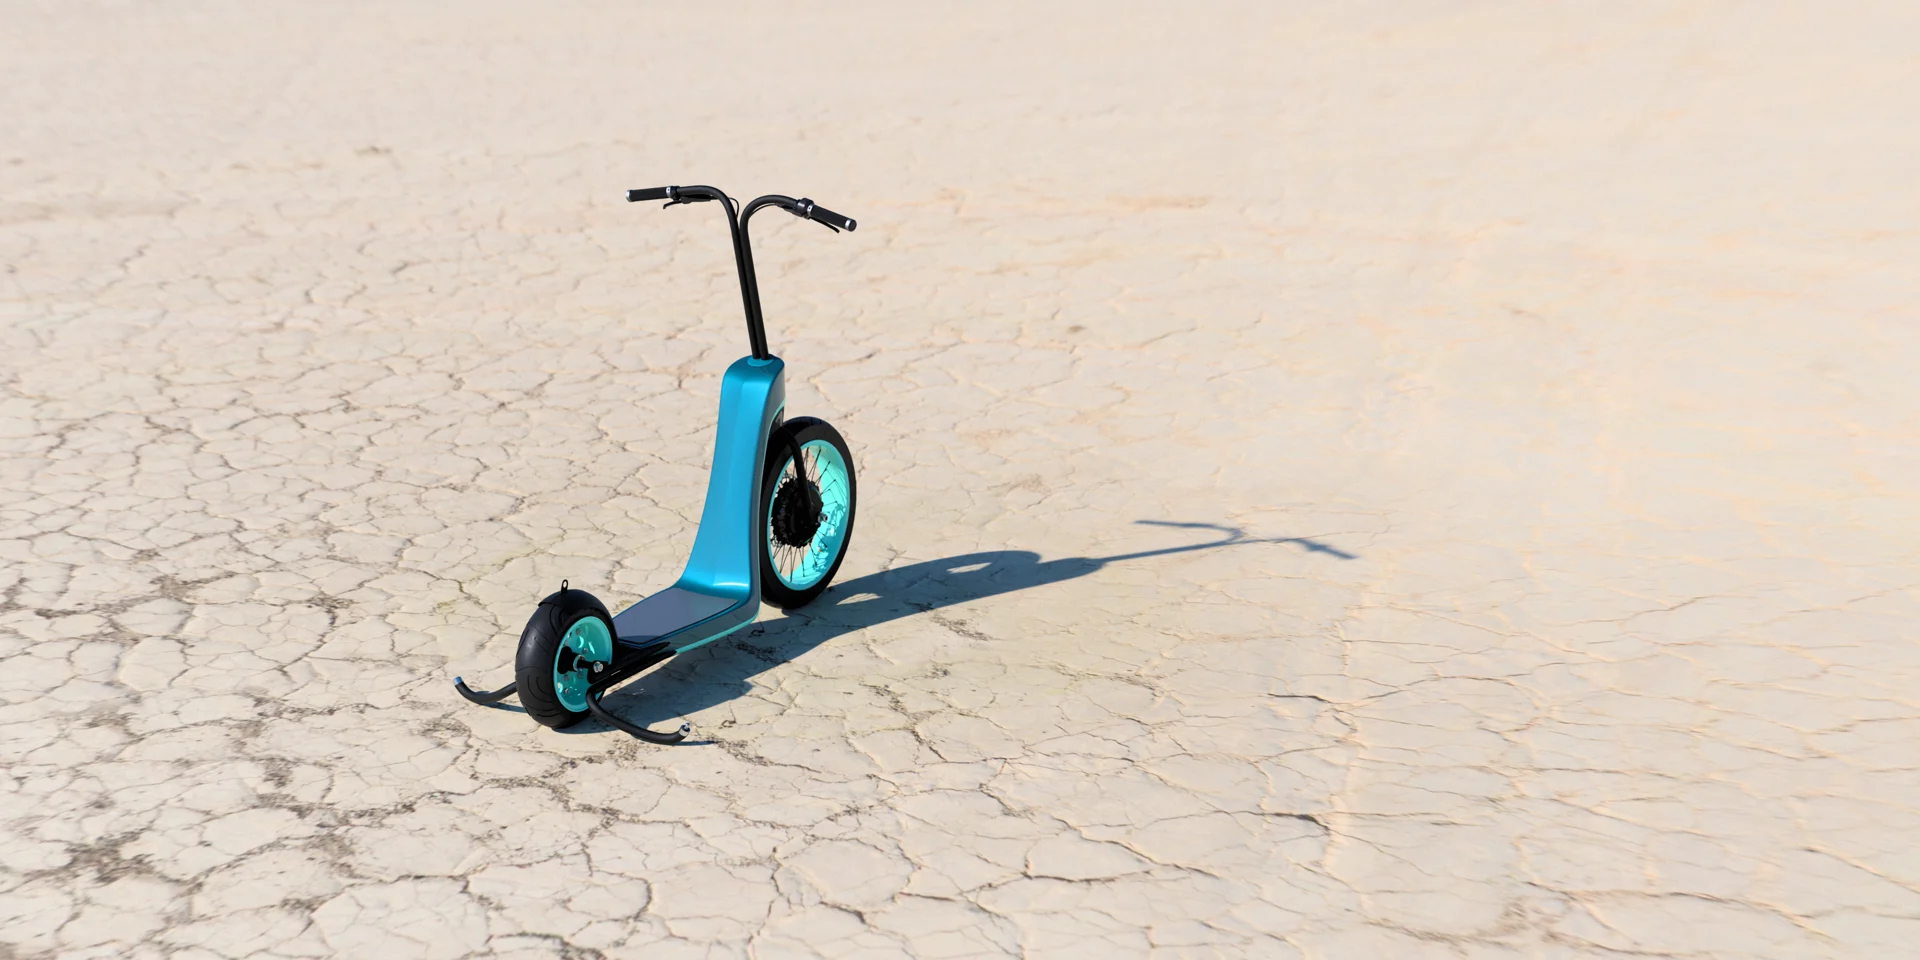
A more stable parking concept
The kickstand concept used two arms integrated with the rear fender. When extended, the arms would form a broad tripod with the front wheel. We also considered motorizing the mechanism to support autonomous parking and reduce the need for active balancing while stationary.