Letting usability shape the design
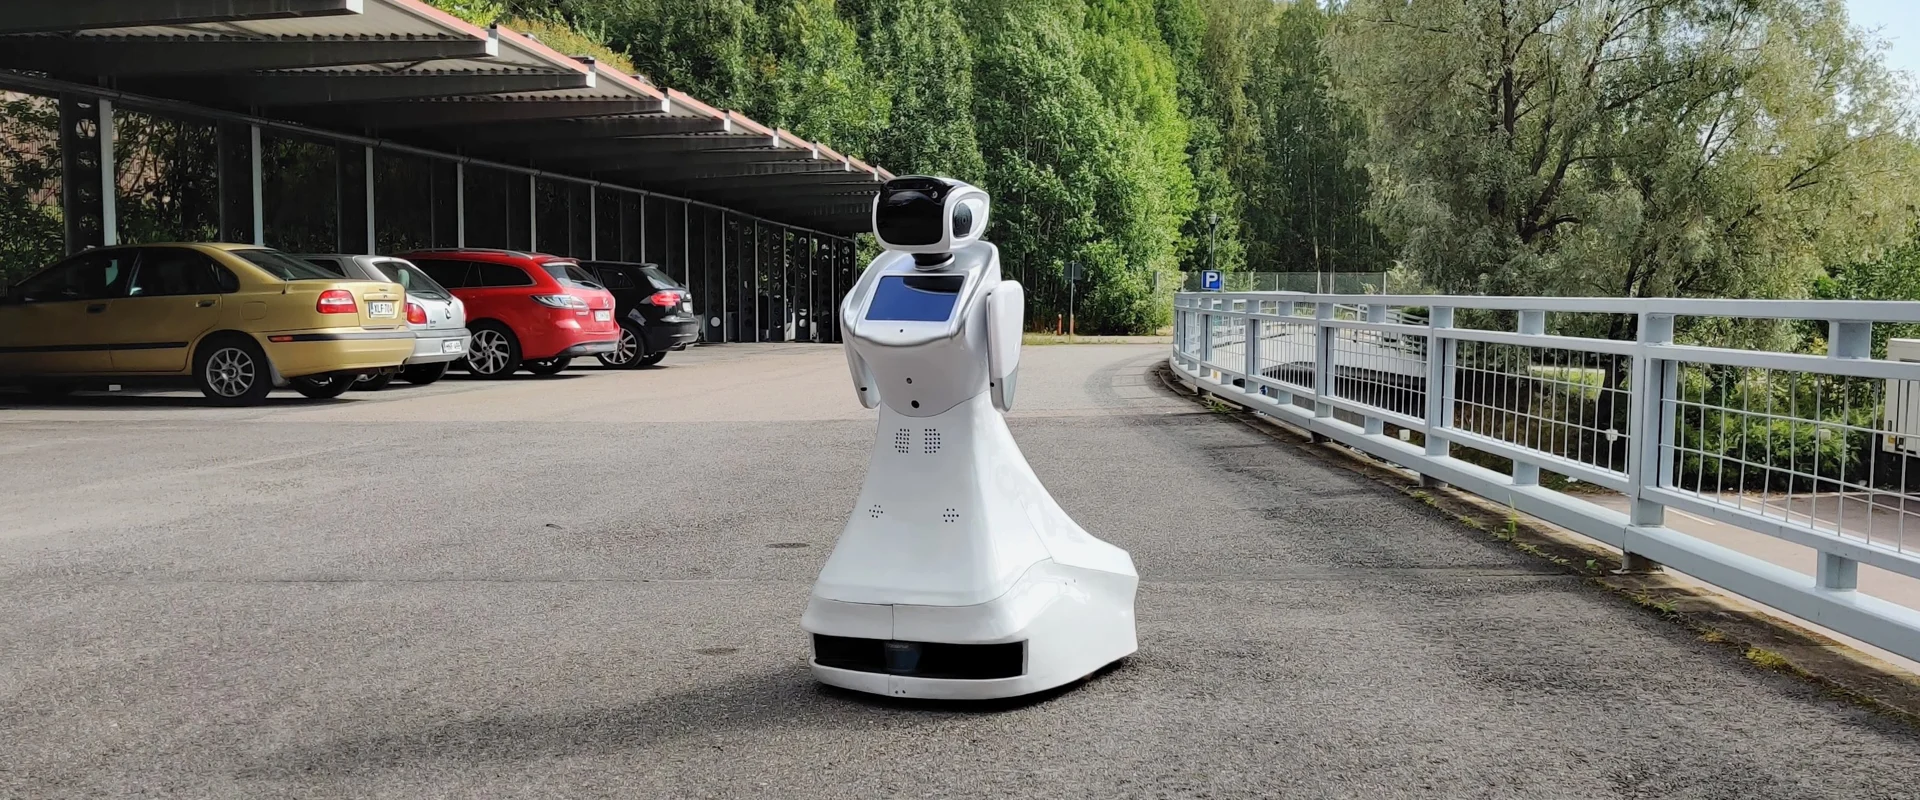
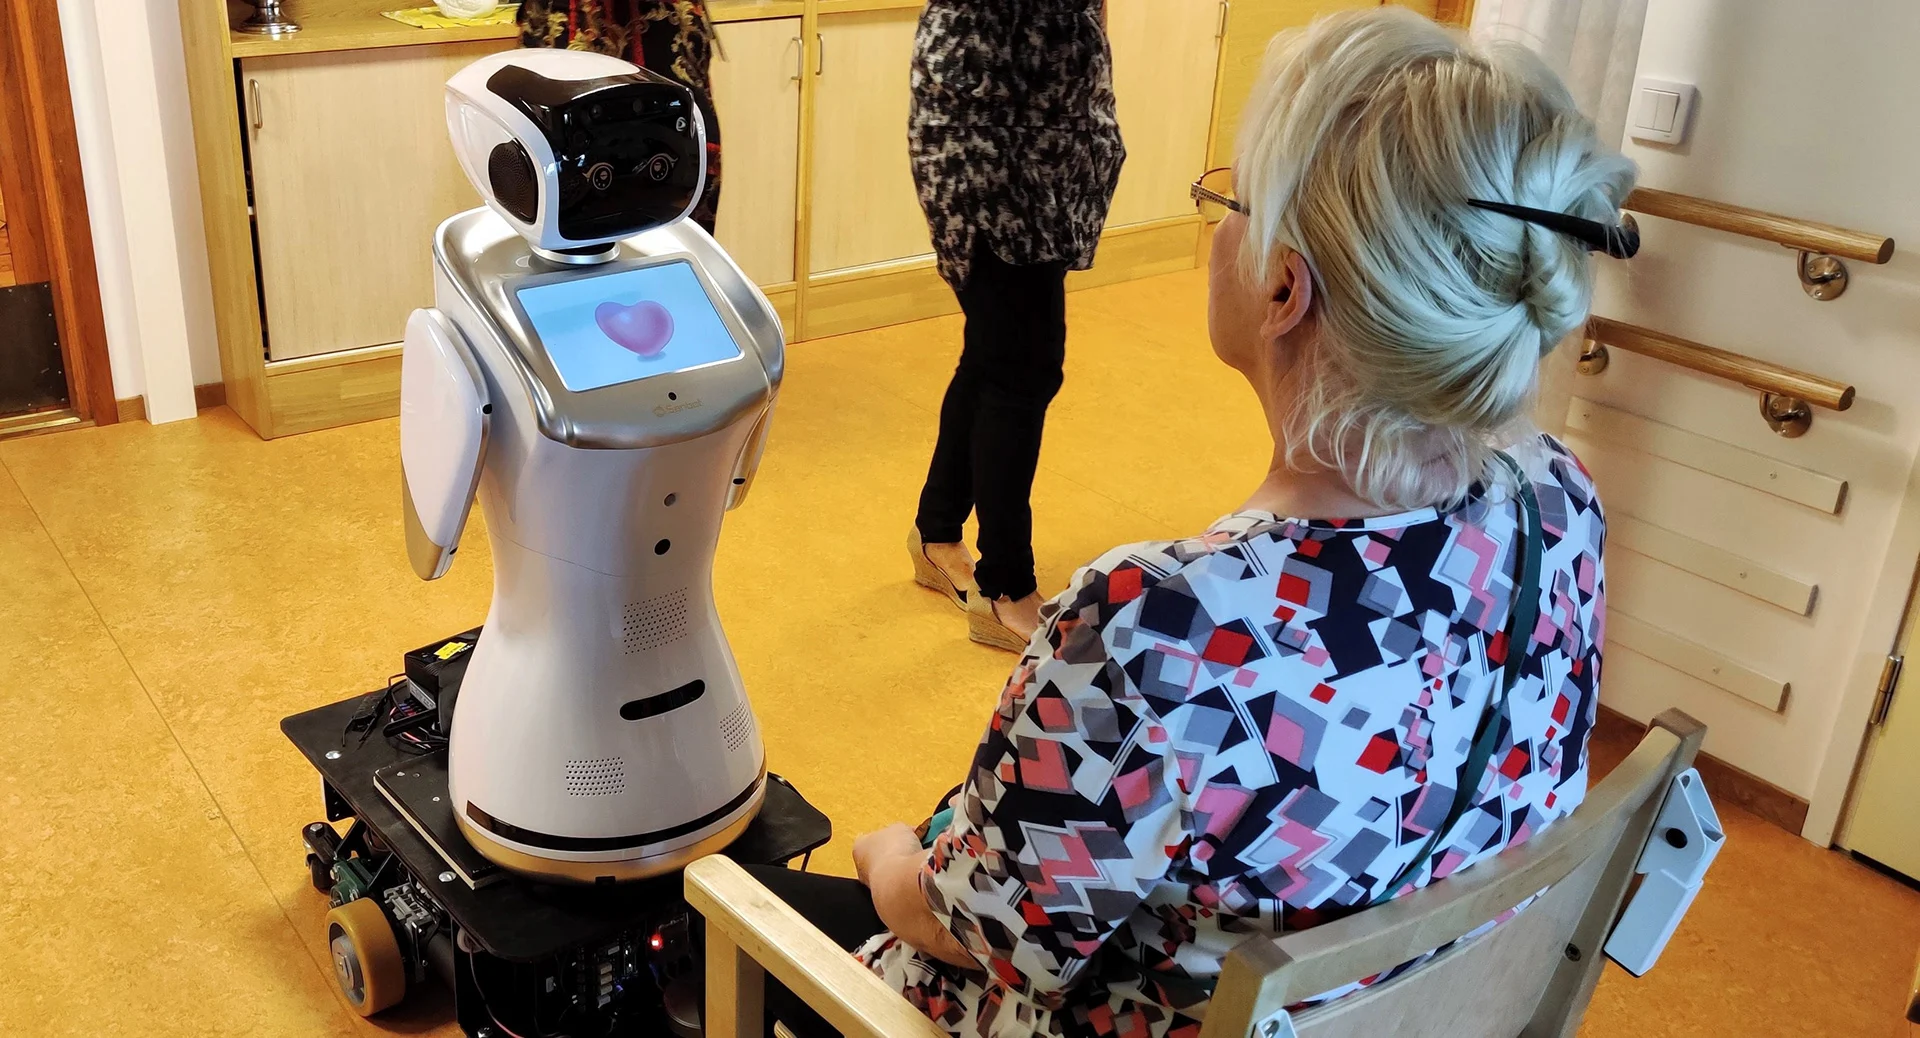
After the initial sketches, we observed the robot in its intended environment. This revealed a practical issue: when mounted on the navigation platform, the robot's touchscreen would be difficult for some older users to reach. We adjusted the concept to tilt the robot toward the user.
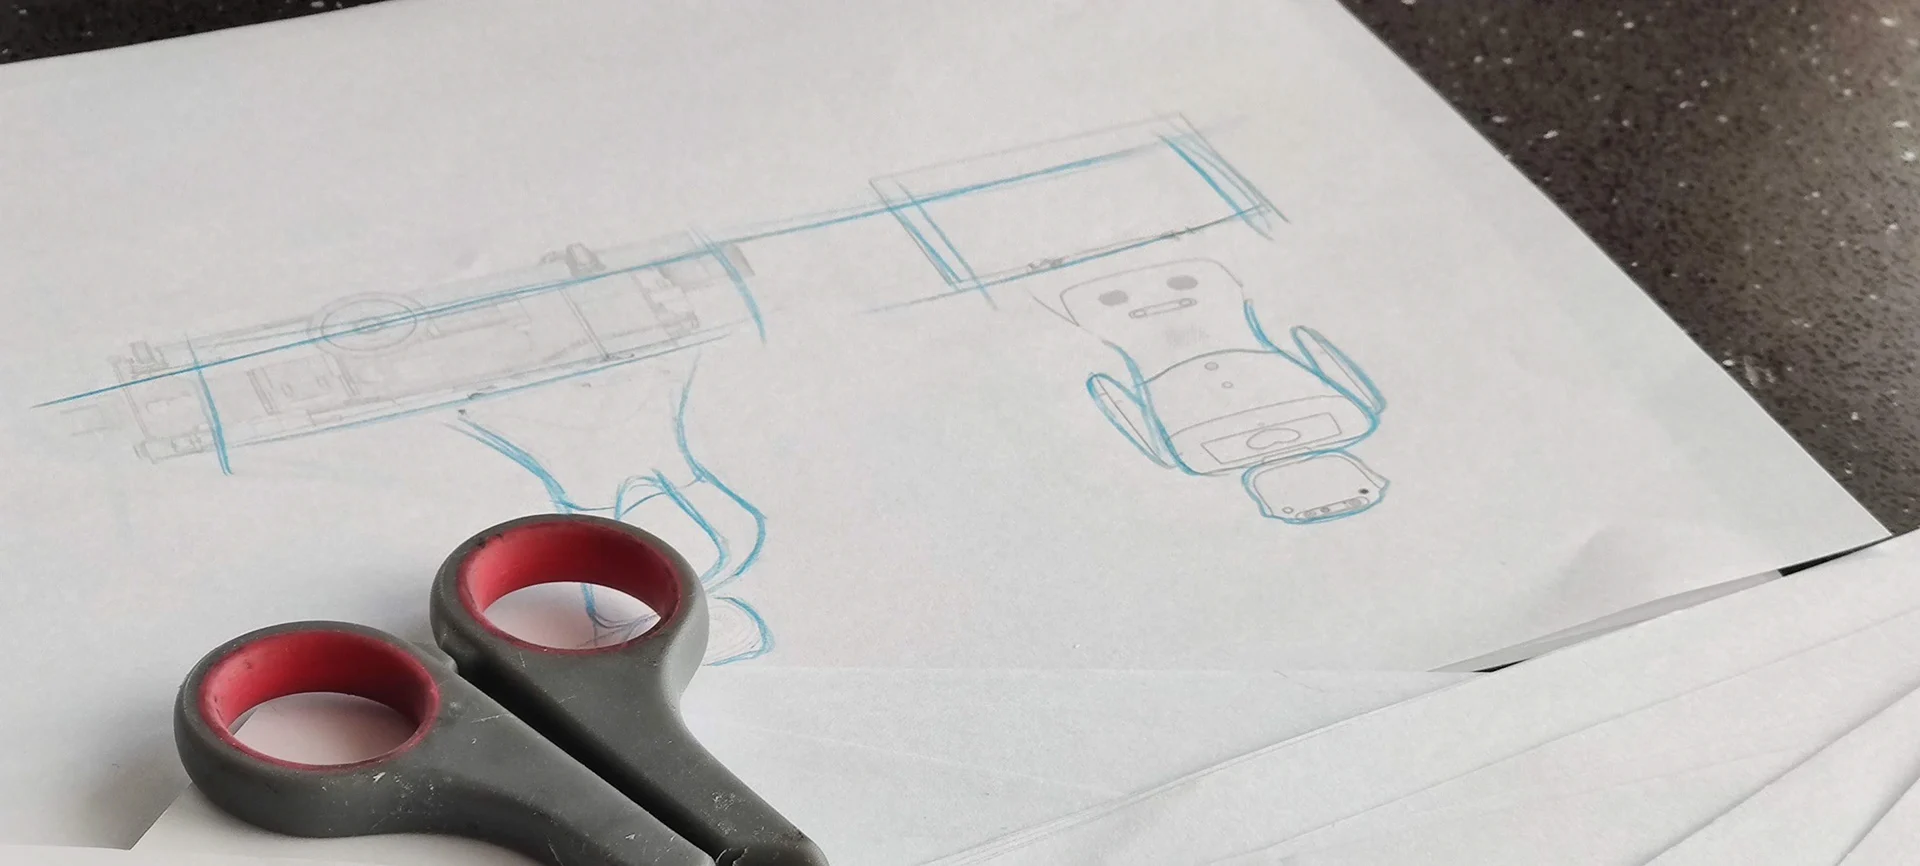
Developing the shell around the hardware
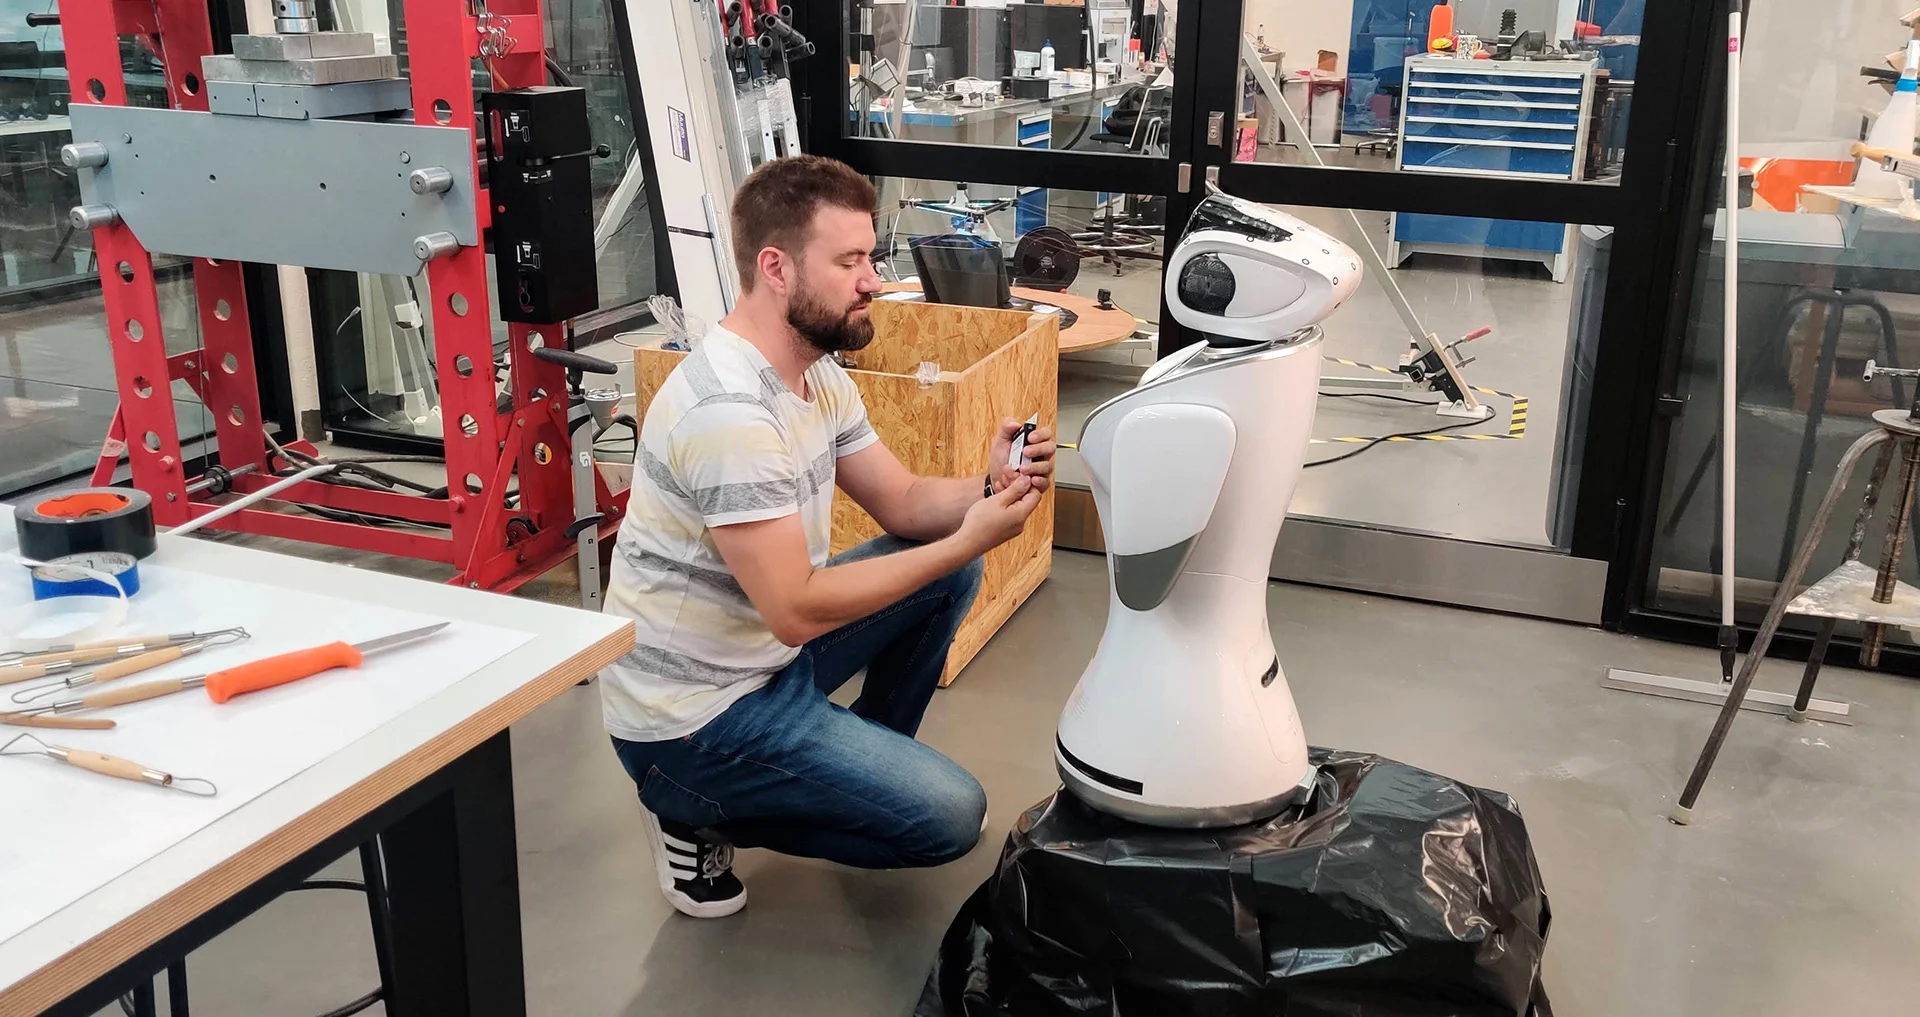
We built quick mockups, presented them to the client and used 3D scans and measurements of the supplied hardware to develop the design.
From surface model to physical prototype
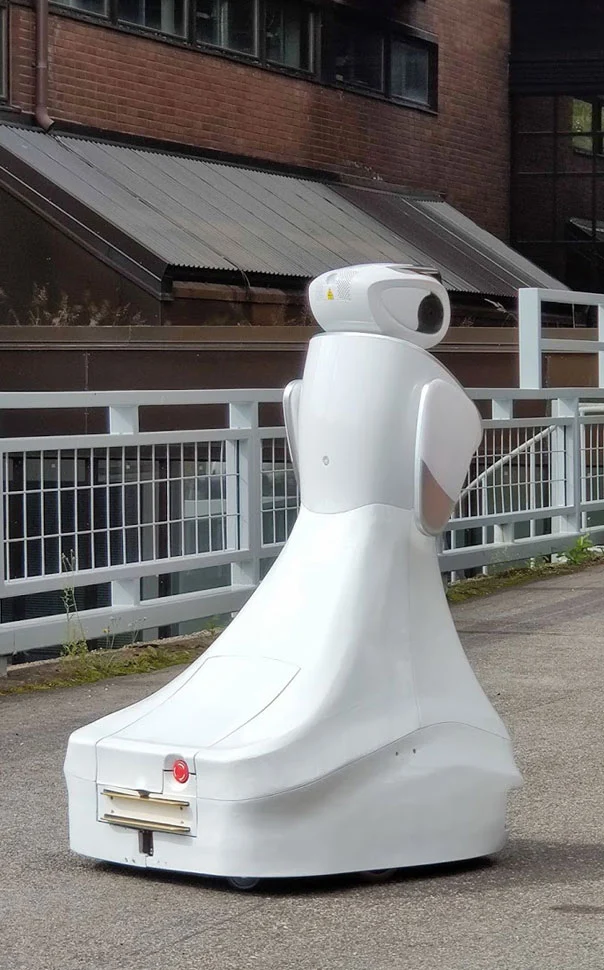
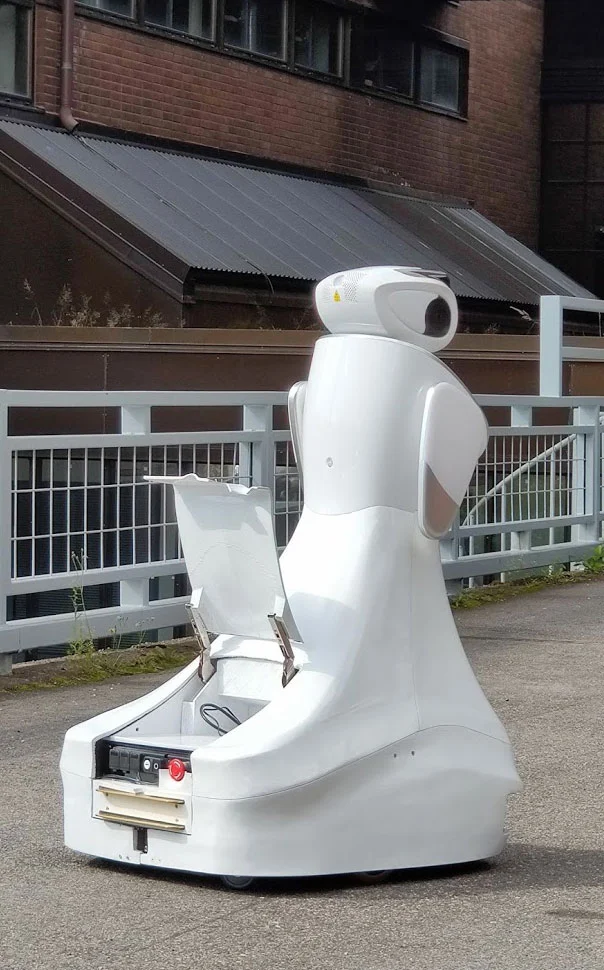
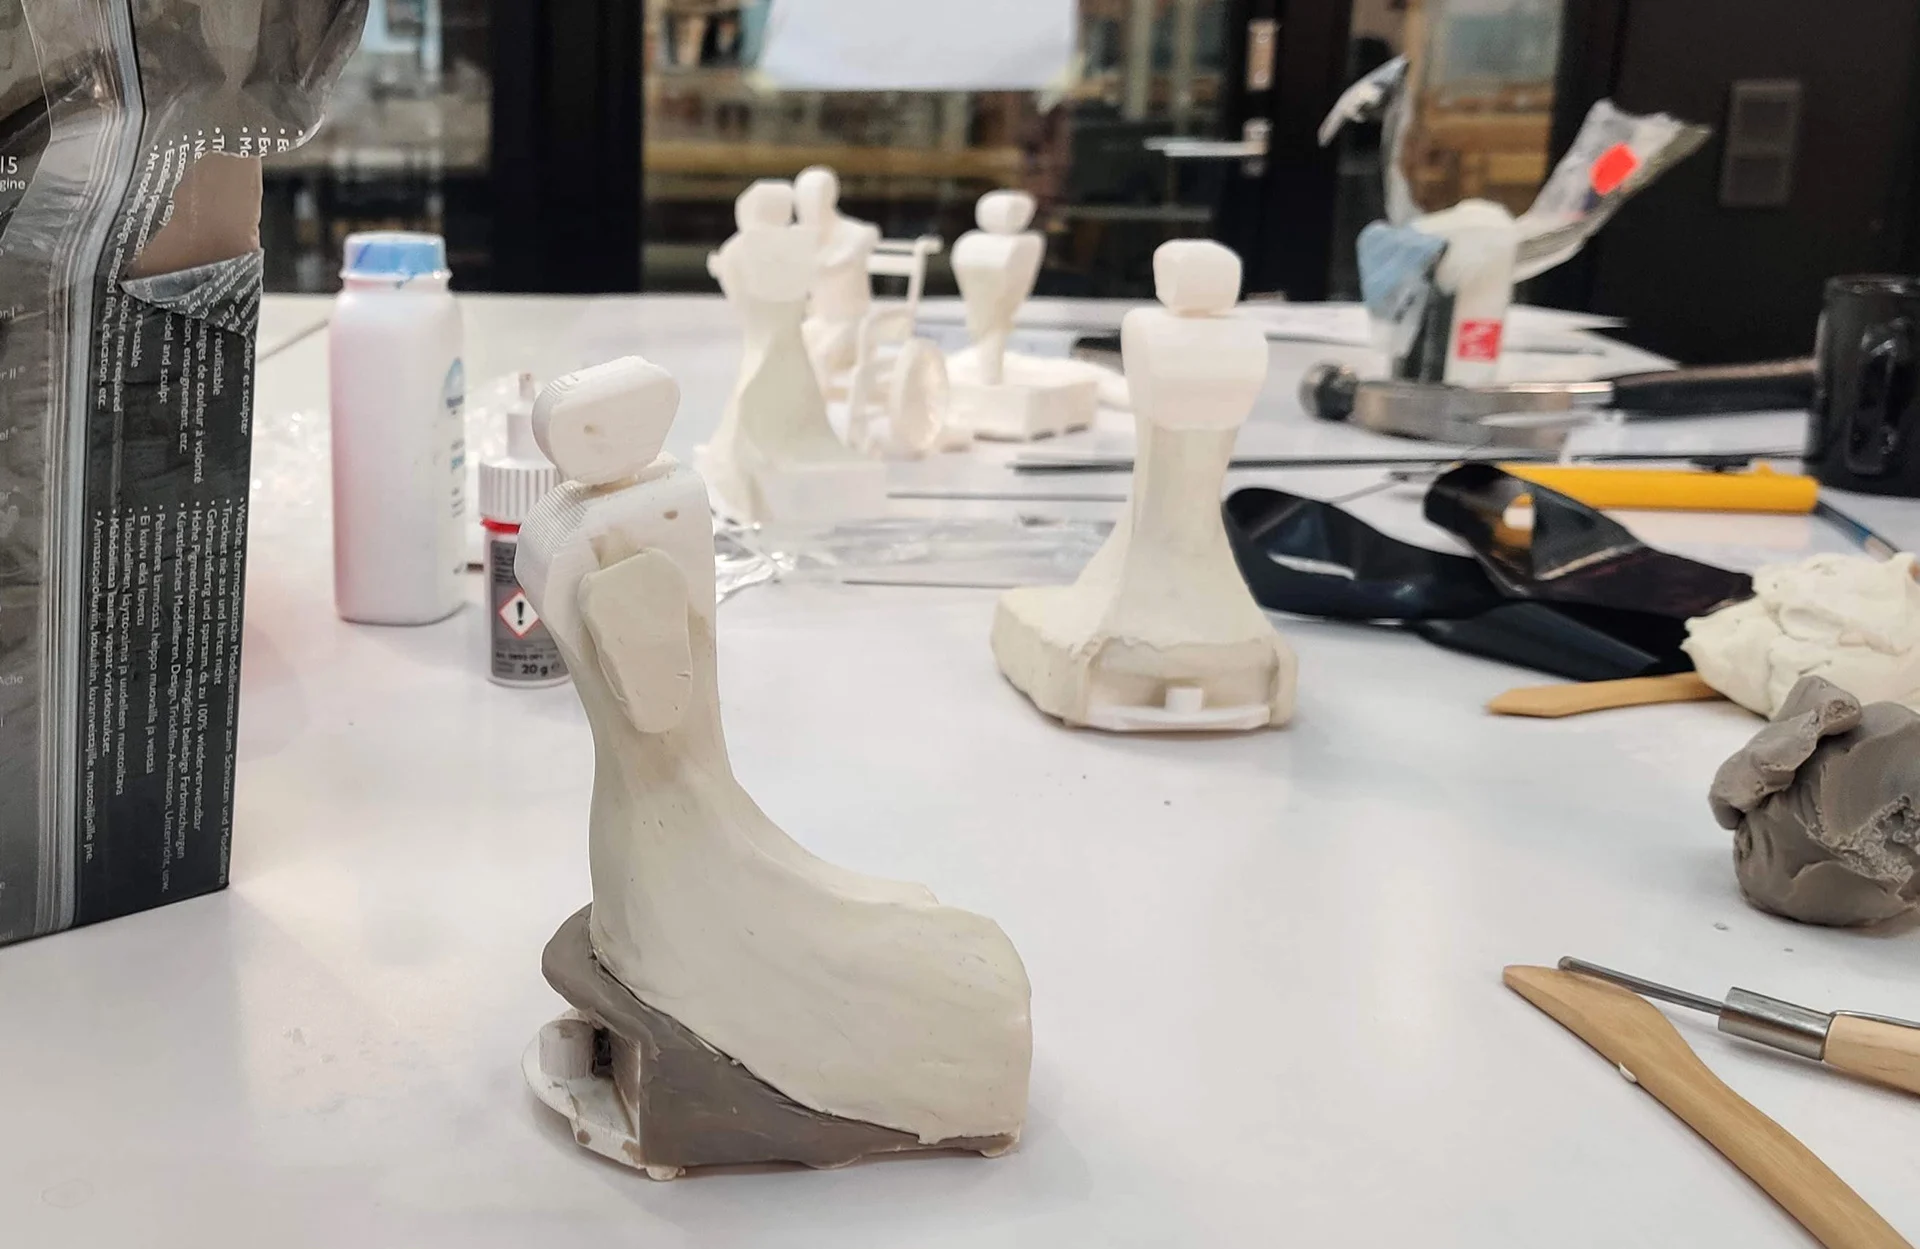
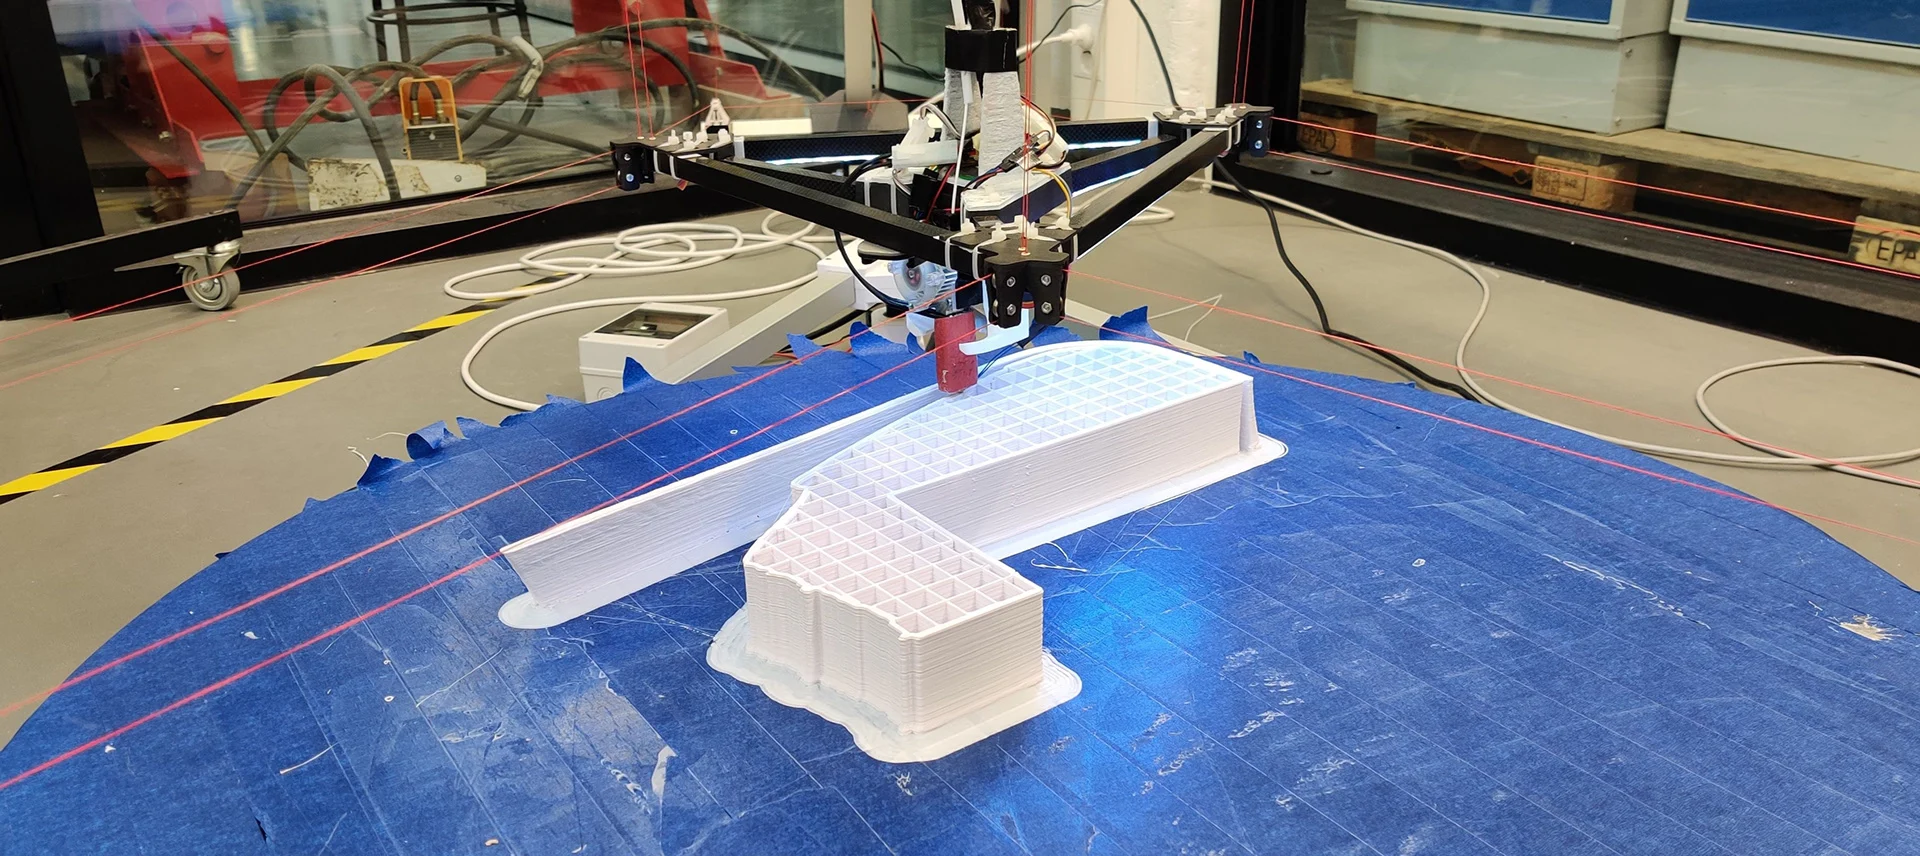
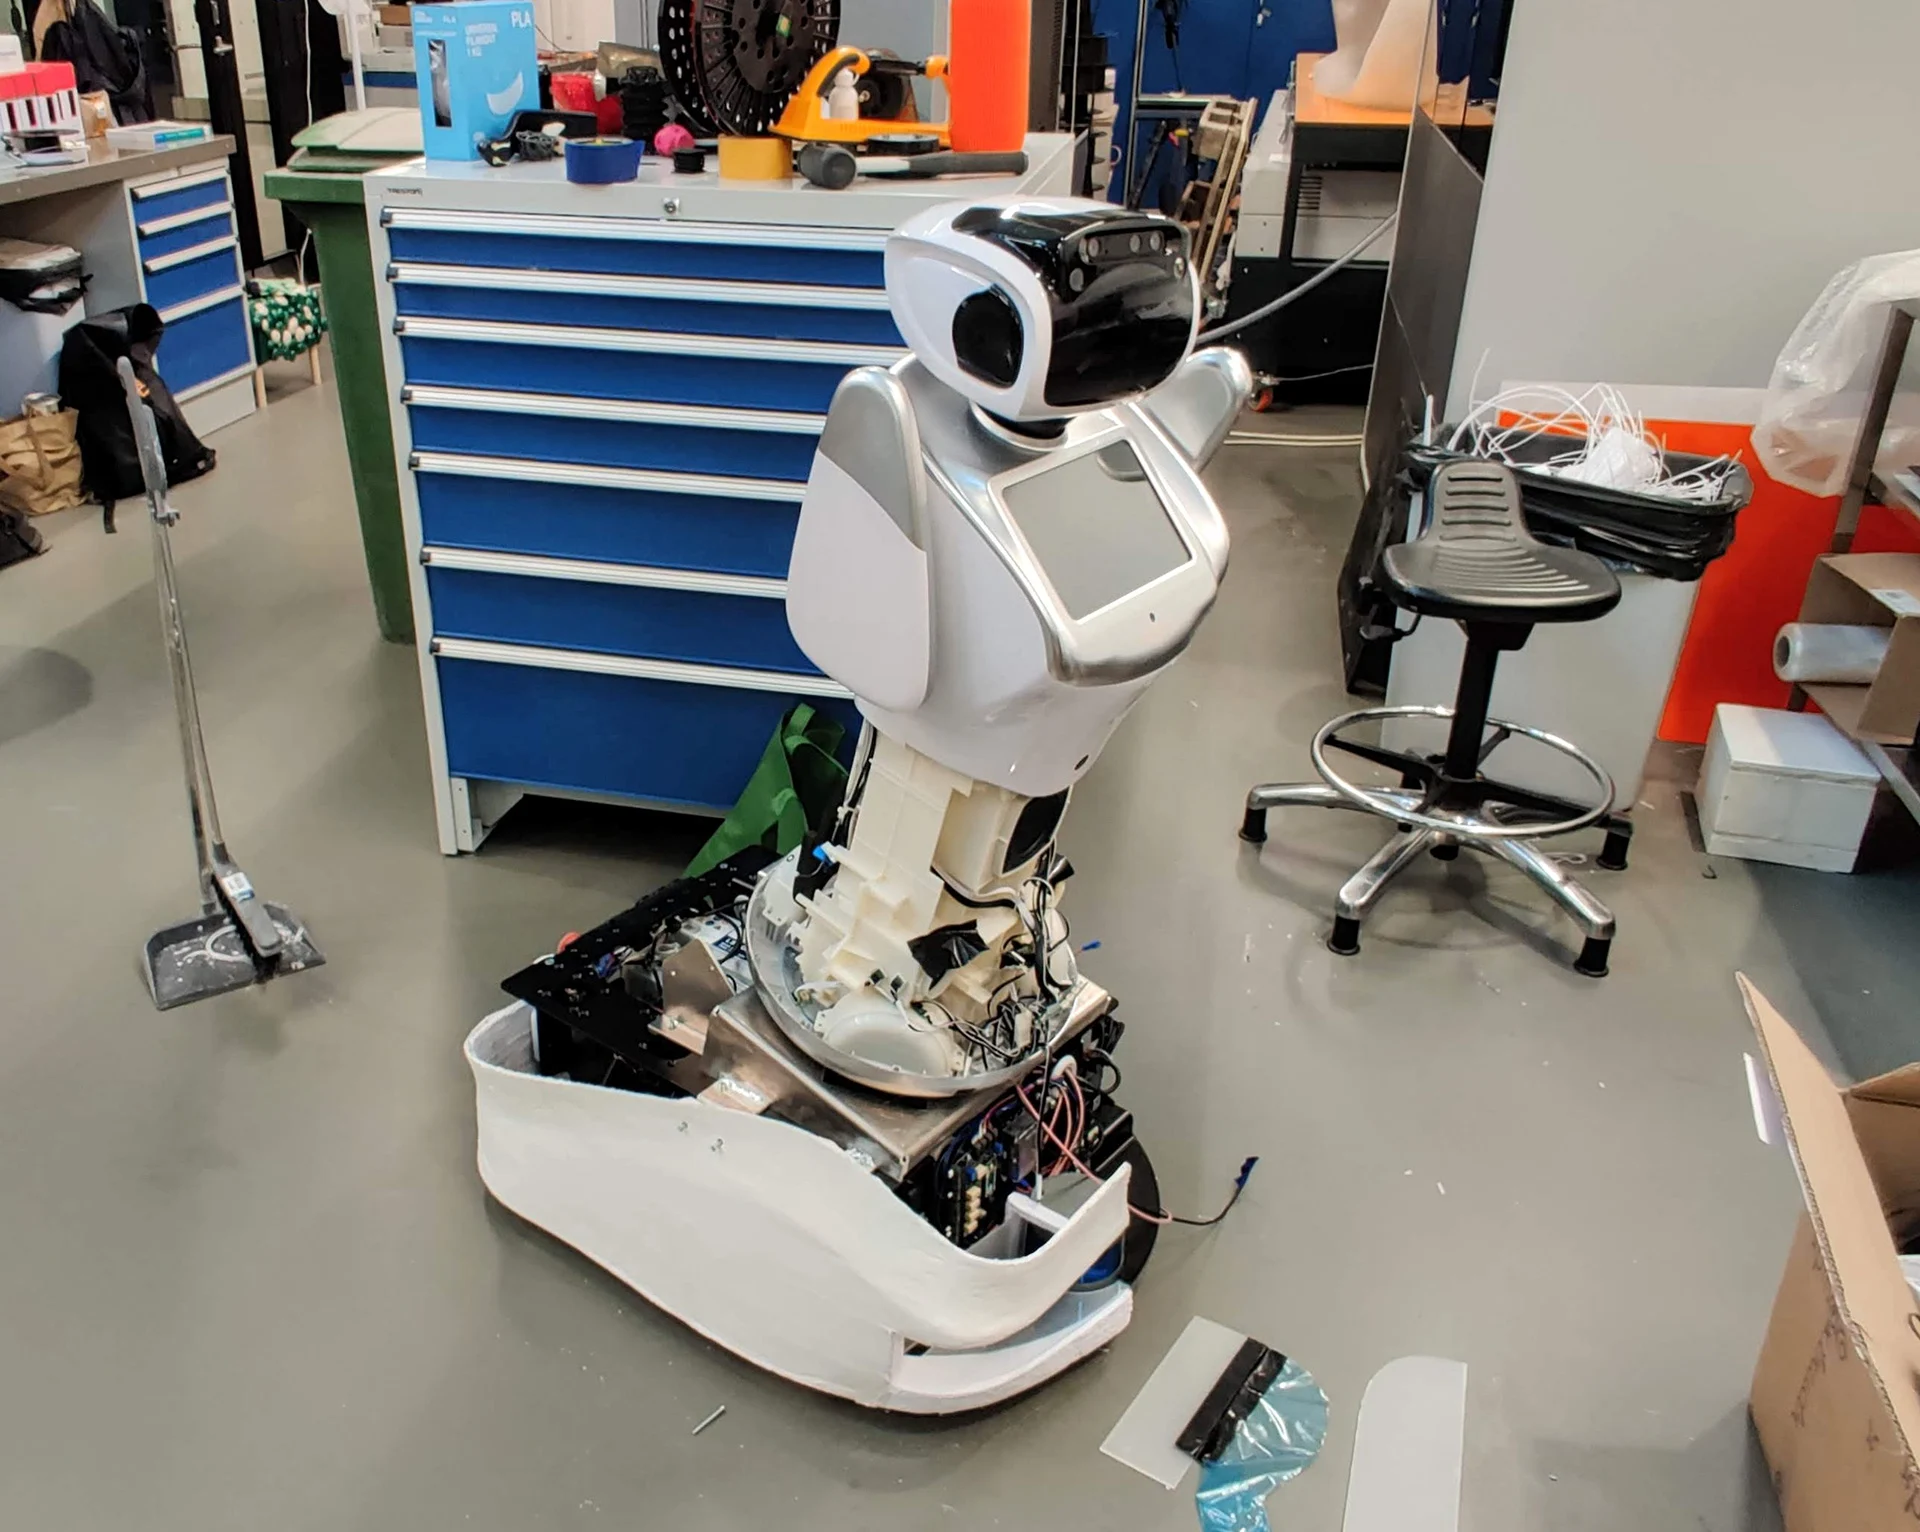
Jessica developed the surface model, which I then converted into a solid model suitable for 3D printing. I divided the shell into five sections and added fixing points. We also incorporated a compartment for small items the robot might need to carry.
The finished prototype
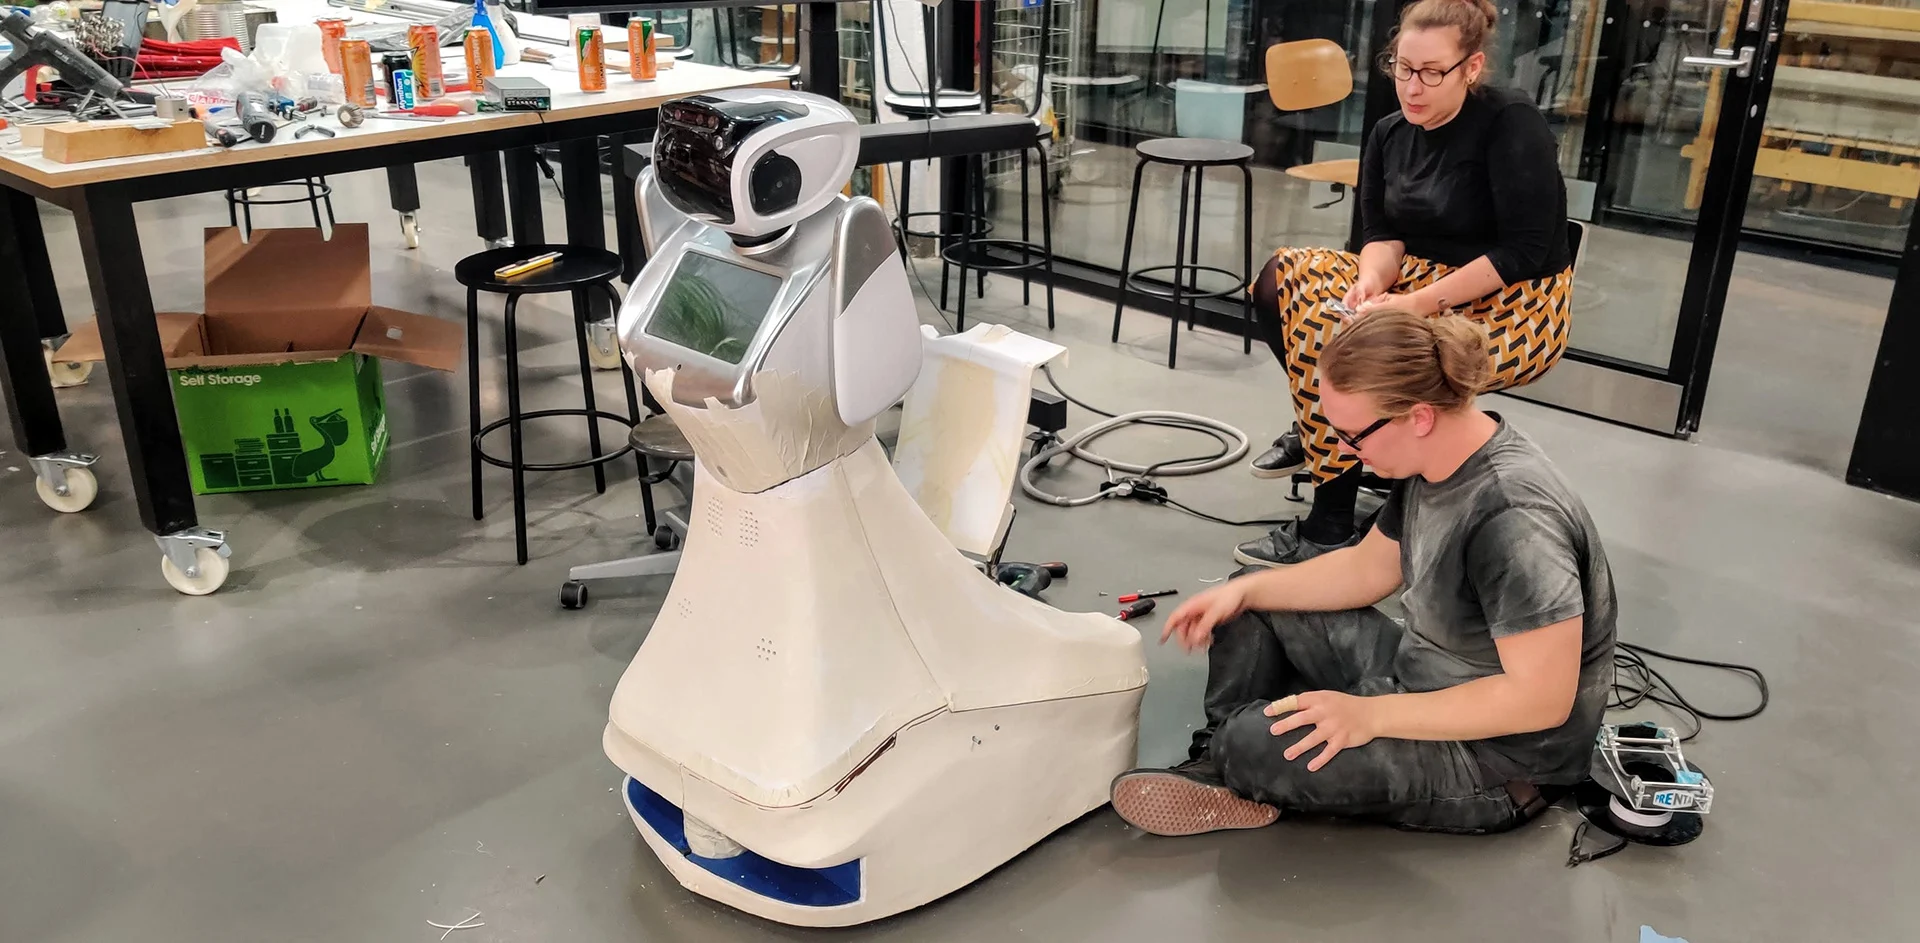
The parts were printed, assembled and adjusted before receiving a white gloss finish. The shell was prepared for a planned trial at Kustaankartano in fall 2019.